A custom high-fidelity vehicle dynamics simulation environment for testing and validation of Autonomous Racing software and a calibration procedure based on experimental data is presented, along with a validation study to further support the quality of the proposed framework.
Abstract
We present a custom high-fidelity vehicle dynamics simulation environment for testing and validation of Autonomous Racing software. The digital twin of the autonomous vehicle is developed in Dymola, using racecar dynamics modeling libraries to build a complete multi-body model. A 3D road surface, including elevation profiles and curbs, is implemented using the Curved Regular Grid (CRG) standard. The model is exported from Dymola as a Functional Mock-up Unit (FMU) and integrated into a custom software-in-the-loop simulator, where communication interfaces with the autonomous racing stack were developed in C++. A calibration procedure based on experimental data is also presented, along with a validation study to further support the quality of the proposed framework. The simulator runs in real time on a portable computer and provides reliable ground truth for algorithms validation prior to real-world deployment.
The modeling of lightweight unmanned ground vehicles (UGVs) with elastomeric tracks presents a challenge due to nonlinear contact mechanics and compliance characteristics that differ significantly from heavy steel-tracked platforms. This study validates a high-fidelity multibody dynamics model of a lightweight tracked...
Dawid Tomica, L. Śnieżek, A. Rubiec et al.· Applied Sciences· 0 citations
Representative coordination and formation scenarios further show that the platform can support scalable multi-BAUV algorithm development and performance evaluation and show close agreement between the modified and original models.
This paper presents MAVES (Matlab Aerial Vehicle Simulator), a nonlinear reduced-order simulation environment for analyzing and testing planar vertical take-off and landing (VTOL) dynamics. The simulator models rigid-body dynamics including thrust-coupled translational and rotational motion, first-order motor dynamics,...
Tolga Özaslan· Bitlis Eren Üniversitesi Fen...· 0 citations
A modular, high-fidelity simulation framework for the development and benchmarking of flight control strategies in fixed-wing aerial robots operating near the ground that models full 6DoF rigid-body physics, semi-empirical ground-effect aerodynamics, actuator dynamics, sensor noise, and environmental disturbances.
Matteo El Hariry, Pedro U. Lima, Andrej Orsula et al.· 0 citations
This paper presents a novel whole-body Backstepping control strategy for safe quadcopter path-following. The proposed approach introduces an integrated control scheme that combines a translational guidance controller with a rigid-body attitude controller. To guarantee asymptotic path convergence, the method utilizes a...
Arthur H. D. Nunes, Arthur Da C. Vangasse, G. Raffo et al.· 0 citations
Related blog posts
Microsoft Research Blog· microsoft.comNov 12, 2026
What's new in research at Microsoft? Host Anson Ho explores the latest, including AI-powered universal translation, a breakthrough in a 31-year-old mathematics challenge, and advances making AI coding agents faster and more efficient. The post Microsoft Research Focus – Edition #98 appeared first on Microsoft Research.
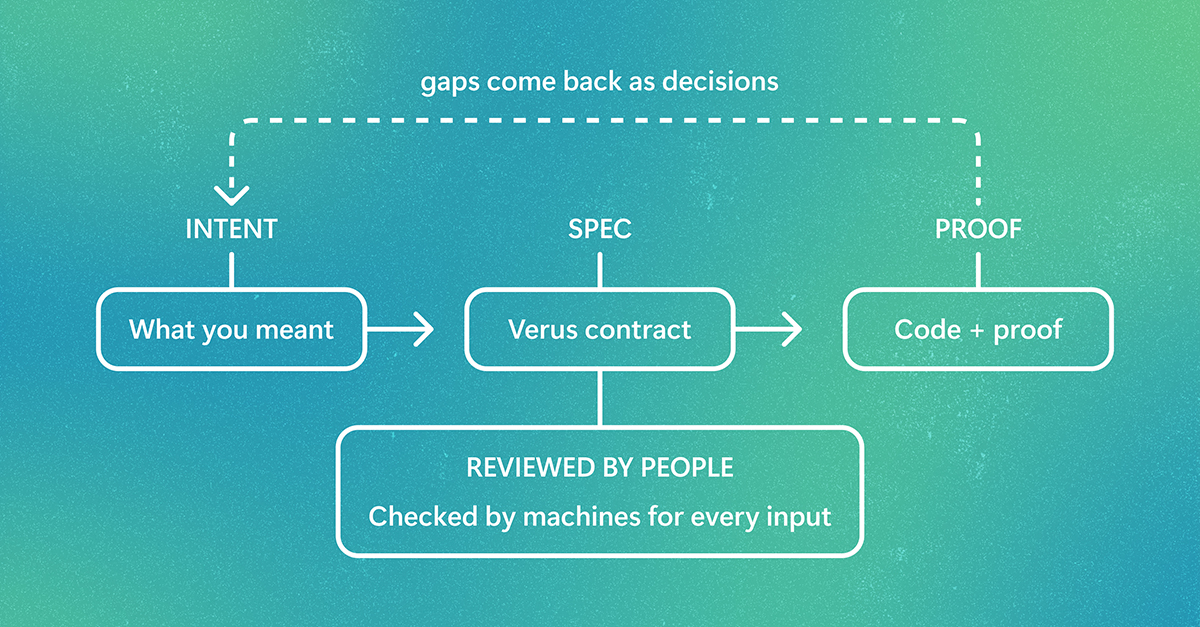
AI agents can generate code at a scale that’s hard for humans to review line-by-line. PDD Kit helps ensure the code is doing what the developer intended by creating formal specifications and testing against them. It converts developer intent into a Verus specification, proves AI-generated code meets it for every input, and uses tests where proofs aren't practical. Developers review intent, not every line. The post Formally verifying agent-written full-stack web apps with PDD Kit appeared first o…