Skip to content

Demand-Aware Multi-Area Multi-UAV Empowered Mobile Edge Computing: A Joint Energy and Delay Optimization

Oct 2026 · IEEE Transactions on Mobile Computing · Vol 25, pp. 18103-18116 · 0 citations · 41 references

Abstract

Multi-UAV-assisted mobile edge computing (MEC) has emerged as a promising paradigm for smart city infrastructures, where multiple uncrewed aerial vehicles (UAVs) collaboratively provide airborne computing services by bringing computational resources closer to end users, thereby reducing both communication costs and service latency. Existing multi-UAV-assisted MEC approaches typically employ fixed allocation schemes that predetermine the number of UAVs for a service area, failing to adapt to heterogeneous regional demands and leaving substantial UAV fleet capacity underutilized. To address this issue, we consider a multi-area multi-UAV-assisted MEC scenario where the control center jointly optimizes UAV deployment, user association, and resource allocation for each service area based on actual regional demands. This optimization enables multiple UAVs to be allocated to high-demand areas while assigning fewer UAVs to low-demand areas, thereby maximizing the service capacity of the entire UAV fleet. We formulate the optimization problem as a constrained multi-objective optimization problem (CMOP) that simultaneously minimizes the total system energy consumption and average user task completion delay, subject to deployment, user association, resource capacity, and task completion delay constraints. To effectively solve this CMOP, we propose a constrained multi-objective evolutionary algorithm that systematically reconstructs infeasible solutions into feasible ones through a constraint-guided solution reconstruction mechanism, thereby accelerating convergence toward feasible regions. Experimental evaluations demonstrate that our algorithm outperforms five state-of-the-art baseline methods in solution diversity and convergence performance. The results validate the effectiveness of flexible UAV allocation strategies, establishing a foundation for demand-aware resource provisioning in multi-UAV-assisted MEC systems.

View source

Similar papers

#edge computing Open access Sep 2026

Joint Optimization of Offloading, Phase-Shift, Trajectory and Resource Allocation in Priority-Aware IRS-Assisted UAV-MEC Systems

This paper considers task priority and integrates intelligent reflecting surface (IRS) into traditional UAV-MEC to enhance offloading efficiency and indicates that the system utility of the proposed method is dramatically higher than other benchmark schemes under different scenes.

Liang Zhao, Si-Nong Zhang, Huan Zhou et al. · 0 citations
#edge computing Open access Aug 2026

Collaborative resource allocation in UAV-assisted MEC networks: A heterogeneous MAPPO scheme

This paper proposes a heterogeneous multi-agent proximal policy optimization (MAPPO)-based framework where both user devices and UAVs act as heterogeneous agents and utilizes a centralized training and decentralized execution (CTDE) paradigm to enable collaborative strategies between computing requesters and providers.

Ming Cheng, Canlin Zhu, Jian-Hang Tang et al. · 0 citations
2026

Resilience-Aware Completion Time Minimization in Cooperative Multi-UAV Data Processing System

Recent advances in mobile edge computing (MEC) have transformed unmanned aerial vehicles (UAVs) into intelligent platforms capable of distributed sensing, computing, and communication. However, coordinating multiple UAVs presents significant challenges in task assignment, path planning, and resource allocation. To addr...

Jian-Hua Tang, Ya-Hao Yang, Wei-Jie Hong et al. · 0 citations
#edge computing Book Open access Oct 2026

UAV-Assisted Resource Optimization for Priority-Aware and Trustworthy Services

The rapid expansion of Internet of things (IoT) devices generates increasing service demands that require reliable computation in regions with limited fixed infrastructure. Uncrewed aerial vehicle (UAV)-based mobile edge computing (MEC) systems provide a flexible solution by relocating computational resources close to...

Muhammad Omair Butt, Muhammad Naeem, Waleed Ejaz · 0 citations
Open access 2026

UAV-Assisted Priority-Aware Resource Allocation for DT-Enabled Vehicular Edge Computing Networks

Digital twin (DT)-empowered vehicular edge computing (VEC) enables roadside units (RSUs) to maintain synchronized virtual replicas of vehicles while processing their offloaded computation tasks, yet both services compete for the same limited communication and edge computing resources. This competition becomes critical...

Piyush Singh, Wan-Jen Huang · 0 citations
#edge computing Open access Aug 2026

Distributed Trajectory Planning and Resource Allocation for Dynamic Multi-UAV Collaborative Computing

A hierarchical joint optimization algorithm is developed within a multi-agent deep reinforcement learning (MADRL) framework to coordinate UAVs and MTs in a distributed manner and outperforms other benchmarks under varying network scales and capabilities by jointly optimizing UAV operations and resource utilization.

Tian-Kui Zhang, Wenlong Xu, Tian-Yi Shi et al. · 0 citations

Related blog posts

Microsoft Research Blog Oct 21, 2026

Solving a 31-year-old grand challenge in mathematics – the KLS conjecture

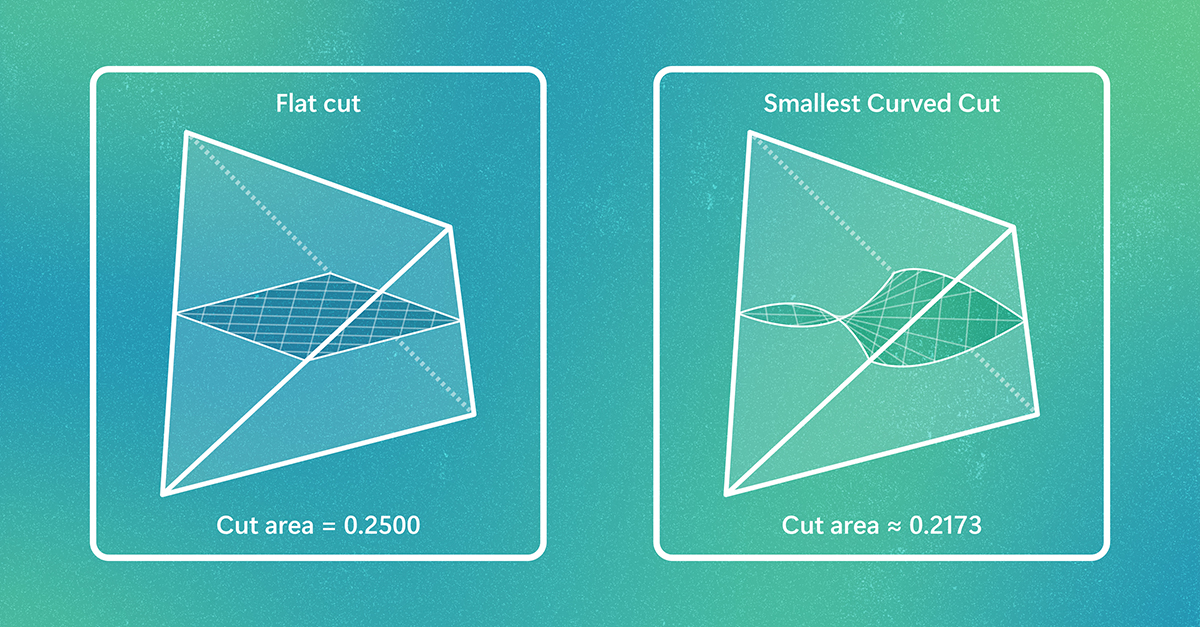
For decades, a fundamental question about the difficulty of computing in high-dimensional spaces has resisted proof. New research resolves this question, removing a major theoretical obstacle to understanding the efficiency of randomized algorithms used across science and computing. The Kannan–Lovász–Simonovits (KLS) conjecture was proposed in 1995. It asks whether, for a broad class of high-dimensional […] The post Solving a 31-year-old grand challenge in mathematics – the KLS conjecture appear…

MIT News · Artificial Intelligence Oct 15, 2026

AI model decodes the language cells use to communicate

A new computational approach reveals how cells communicate to assemble into tissues. This could accelerate stem cell engineering, improve disease models, and inform therapies.

Microsoft Research Blog Oct 15, 2026

Proof-based general-purpose computing with Magnetar

Zero-knowledge proofs can verify computing results without rerunning workloads or exposing sensitive data. Magnetar helps bring them into the mainstream with support for standard programming languages, major speed gains, and quantum-resistant security. The post Proof-based general-purpose computing with Magnetar appeared first on Microsoft Research.

We use cookies to run the site and, with your consent, for analytics and to show ads. See our Cookie Policy.