UDAV, an Uncertainty-Driven Adaptive VLM Waypoint Planner for UAV-guided UGV navigation is presented, demonstrating that stochastic VLM predictions provide both a stronger nominal route and an actionable uncertainty signal for selectively mitigating large planning errors.
Abstract
Vision-language models (VLMs) can generate routes directly from aerial imagery for off-road navigation, but their predictions provide no indication of reliability. We present UDAV, an Uncertainty-Driven Adaptive VLM Waypoint Planner for UAV-guided UGV navigation. UDAV draws multiple stochastic trajectory predictions, selects their medoid as a self-consistent nominal route, and estimates predictive uncertainty from their spatial dispersion. When the maximum uncertainty across interior waypoints exceeds a threshold, UDAV invokes a reconsideration stage; otherwise, it returns the medoid directly. We evaluate UDAV on 400 held-out trajectory queries from two UAV flights. Stochastic medoid selection reduces the mean average displacement error (ADE) from 147.4 pixels for a deterministic prediction to 115.9 pixels. The complete planner achieves a mean ADE of 110.4 pixels, a 25.1% reduction relative to deterministic planning, while producing valid trajectories for all queries. UDAV also yields the lowest 90th- and 95th-percentile errors among all evaluated configurations, including a higher-budget K=10 consensus baseline. Relative to the K=5 medoid, UDAV reduces these errors from 225.3 and 326.0 pixels to 199.0 and 290.8 pixels, respectively. These results demonstrate that stochastic VLM predictions provide both a stronger nominal route and an actionable uncertainty signal for selectively mitigating large planning errors.
GAOKAO-Bench is introduced, an intuitive benchmark that employs questions from the Chinese GAOKAO examination as test samples, including both subjective and objective questions that contribute a robust evaluation benchmark for future large language models and offers valuable insights into the advantages and limitations...
Xiaotian Zhang, Chun-yan Li, Yi Zong et al.· arXiv.org· 216 citations· ⚡17
This work proposes a HALO that directly maximizes the utility of generations instead of maximizing the log-likelihood of preferences, and suggests that the best loss depends on the inductive biases most appropriate for a given setting, an oft-overlooked consideration.
This work investigates the possibilities of using LLMs in a resume screening setting via a document retrieval framework that simulates job candidate selection and finds that the MTEs are biased, significantly favoring White-associated names in 85% of cases and female-associated names in only 11.1% of cases.
This work shows that orders of magnitude enhancement in performance could be obtained by a combination of hardware improvements and tight quantum-HPC integration and introduces high-performance architectures for quantum-probabilistic computing with custom-designed accelerators to tackle today's industry-scale classical...
Masoud Mohseni, Artur Scherer, K. Johnson et al.· arXiv.org· 121 citations· ⚡9
This paper presents a comprehensive overview of the Ultralytics YOLO family, emphasizing architectural evolution, benchmarking, deployment, and emerging directions from YOLOv5 through YOLO27, and examines detection, segmentation, depth, classification, pose, oriented detection, tracking, export, quantization, and deplo...
A novel threat is unveiled in which attackers steer the RAG system's response by injecting malicious passages into its knowledge base, enabling the attacker to steer the response without altering the user input or modifying the RAG weights.
Jiaqi Xue, Meng Zheng, Yebowen Hu et al.· arXiv.org· 109 citations· ⚡8
Related blog posts
MIT News · Artificial Intelligence· news.mit.eduJul 30, 2026
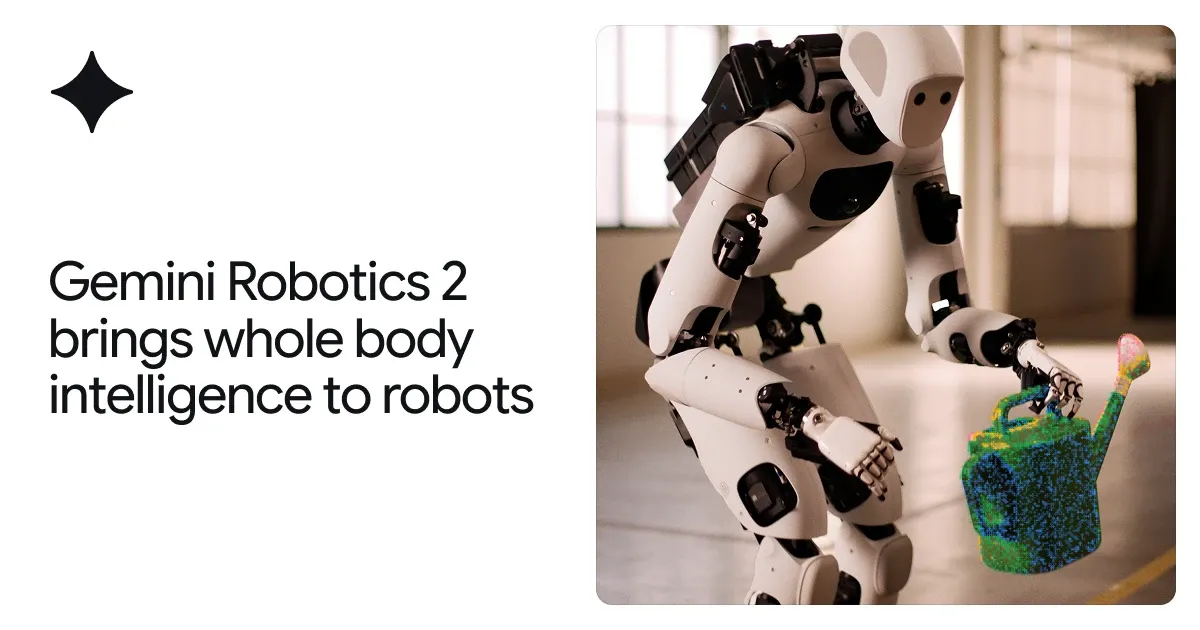
From feet to fingertips — we are teaching robots intelligent whole-body control, fine dexterity, and teamwork to complete a broad range of complex tasks.
MIT News · Artificial Intelligence· news.mit.eduOct 13, 2026
Machine-learning networks can learn without detailed instructions from a designer. Those that do may offer insight into how the brain reorganizes itself during learning.