World-Action Models (WAMs) improve robotic manipulation by conditioning action generation on predicted future observations, but future prediction adds further inference overhead to already expensive iterative action generation. Action chunking can amortize this cost over multiple actions, yet performance degrades over long execution horizons because later actions remain conditioned on stale observations. We introduce STAIRCASE POLICY, a streaming inference and training framework that turns a flow-matching VLA into a JEPA-style WAM and partitions a large action chunk into sub-chunks at staggered denoising stages. Near-term actions are executed as soon as they become available, while later actions continue to be refined. At each sub-chunk boundary, the future latent is re-predicted from the latest observation and used to update all unexecuted actions, enabling long-horizon execution without repeated full policy inference. The resulting future-prediction error can further serve as a signal for adaptive chunking. S-WAM achieves 97.7% on LIBERO and 87.9% on LIBERO-Plus, and improves performance across multiple policy backbones and real-robot tasks. It reaches 292.7 executed actions per second, $3.62\times$ the throughput of conventional execution at comparable accuracy, while reducing time-to-first-action from 123.6 to 73.3 ms. With additional inference optimizations, throughput further increases to 642.9 actions per second.
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
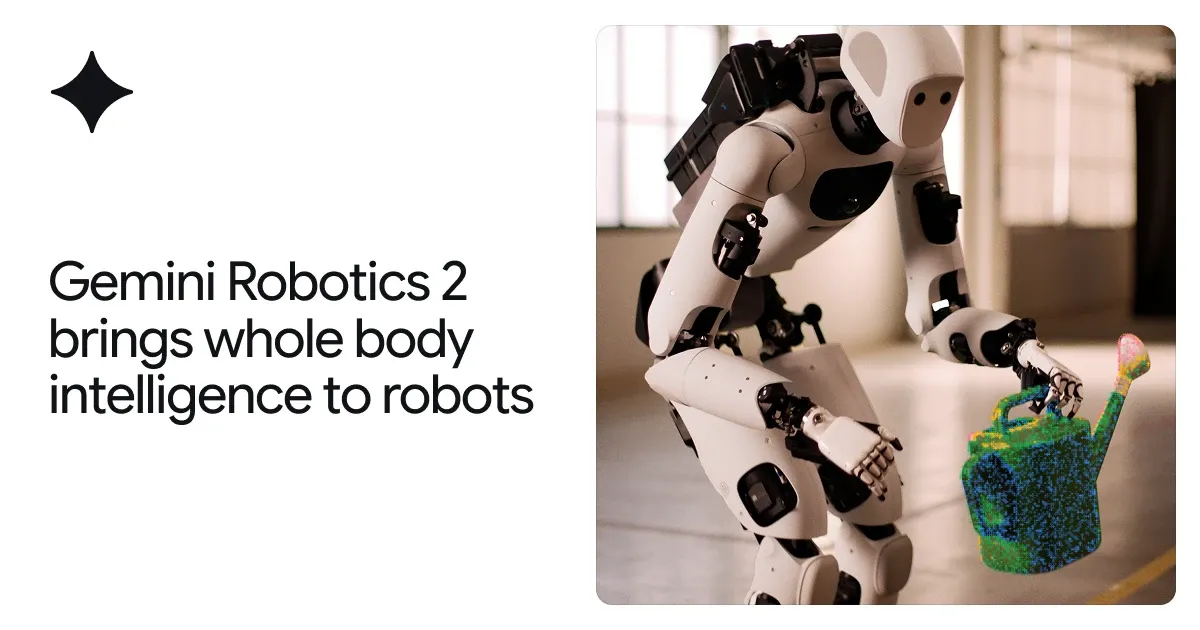
From feet to fingertips — we are teaching robots intelligent whole-body control, fine dexterity, and teamwork to complete a broad range of complex tasks.
Known for his clear and elegant writing style, Bertsekas shaped fields from control and optimization to large-scale computation and artificial intelligence.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.