Timescale Separation Enables Deep Reinforcement Learning Control of Rotating Detonation Engine Mode Transitions
Kristian HolmeJean RabaultRicardo VinuesaMikael Mortensen
Oct 2026· Physical Review Fluids
Machine Learning
Abstract
Rotating detonation engines (RDEs) are a promising propulsion concept that may offer higher thermodynamic efficiency and specific impulse than conventional systems, but nonlinear phenomena, including transitions to oscillatory or chaotic propagation modes, can hinder practical operation. Deep Reinforcement Learning (DRL) has emerged as a promising method for controlling complex nonlinear dynamics such as those observed in RDEs. However, the multi-timescale nature of the RDE system makes direct application of DRL challenging. We address this challenge by reformulating the DRL problem in a moving reference frame that follows the detonation-wave pattern, making the wave structure appear quasi-steady to the agent. This reformulation enables scale separation between fast detonation propagation and slower operating-mode dynamics. We train DRL controllers to modulate spatially segmented injection pressure in a one-dimensional reduced-order RDE model and induce rapid transitions between different mode-locked states. Across a range of actuation periods, initial states, and target modes, controllers trained in the moving frame learn more reliably than those trained in a stationary frame and remain effective over a broader range of actuation periods. These results suggest that symmetry-aware moving reference frame formulations may be useful for related multiscale flow-control problems and that scale separation should be exploited whenever possible to enable DRL control of multi-timescale systems.
This paper investigates developing real-world perception for active agents, proposes Gibson Environment for this purpose, and showcases a set of perceptual tasks learned therein.
F. Xia, Amir Zamir, Zhi-Yang He et al.· 2018 IEEE/CVF Conference on...· 1,069 citations· ⚡112
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
It is proved that any global minimizer of the trajectory balance objective can define a policy that samples exactly from the target distribution, and empirically demonstrate the benefits of the trajectories balance objective for GFlowNet convergence, diversity of generated samples, and robustness to long action sequenc...
Esmeralda S. Whitammer, Moksh Jain, Emmanuel Bengio et al.· Neural Information Processin...· 302 citations· ⚡60
An algorithm is proposed which leverages disentangled semantic factors to generate adversarial perturbation by altering controlled semantic attributes to fool the learner towards various "adversarial" targets.
Haonan Qiu, Chaowei Xiao, Lei Yang et al.· arXiv.org· 208 citations· ⚡17
This work proposes a HALO that directly maximizes the utility of generations instead of maximizing the log-likelihood of preferences, and suggests that the best loss depends on the inductive biases most appropriate for a given setting, an oft-overlooked consideration.
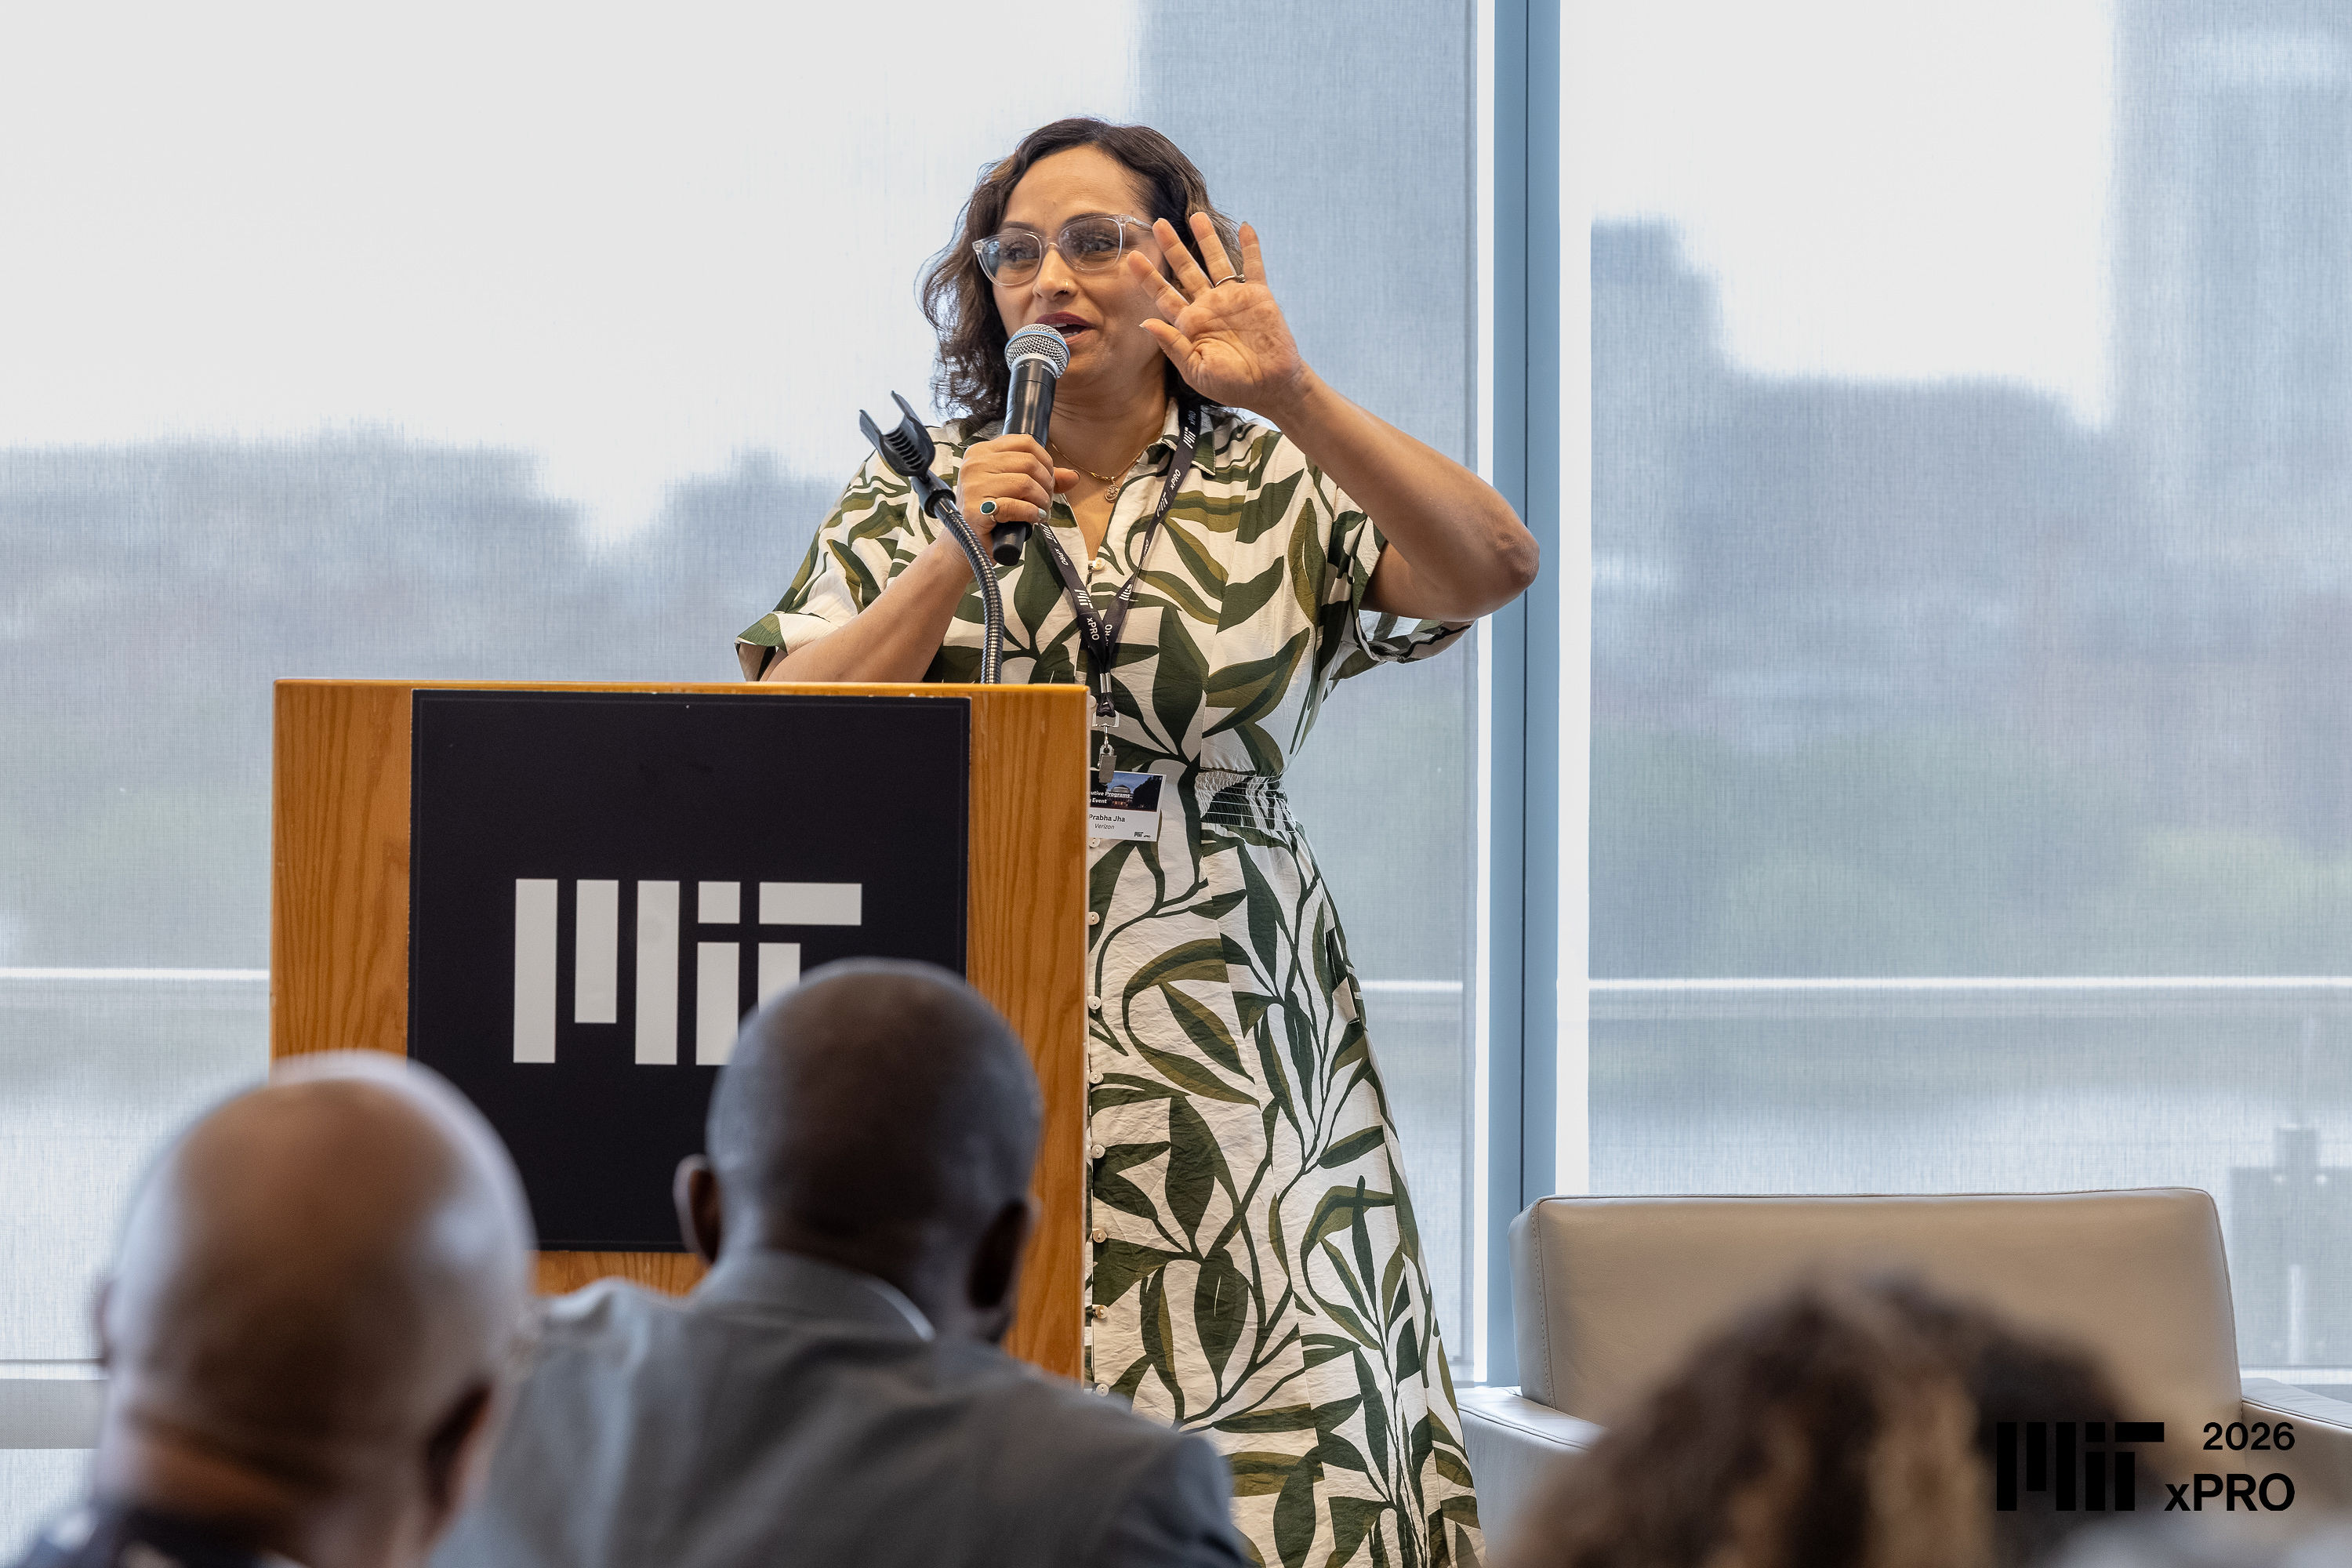
Prabha Jha used her experience with MIT Open Learning’s program for senior executives to develop AI solutions for her employer, Verizon, and to write a book.
Assistant Professor Benjamin Lindquist studies how engineers deliberately injected randomness into early AI, giving rise to deep-learning models that sometimes hallucinate.

