Foundation models and large-scale human data provide rich sources of manipulation intent, but translating this intent into multi-fingered robot behavior remains difficult. Dexterous hands still lack a reusable low-level primitive that reliably establishes contact across tasks and embodiments. We propose GOTT, a reach-acquire-move framework built around a single cross-embodiment contact-acquisition primitive. Given a robot-agnostic object trajectory and a reach specification, GOTT first brings the hand near a task-relevant contact region. The shared closed-loop primitive then establishes stable contact from this approximate initialization, and a pose-conditioned controller tracks the desired object motion. Reach specifications may come from future-aware planning, external models, or human demonstrations, while the primitive and tracking backend remain unchanged. Simulation and real-world experiments show that GOTT is able to establish robust contact across diverse objects, arm-hand platforms, and seen and unseen hand morphologies. It also consistently improves end-to-end task success over open-loop grasp execution.
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
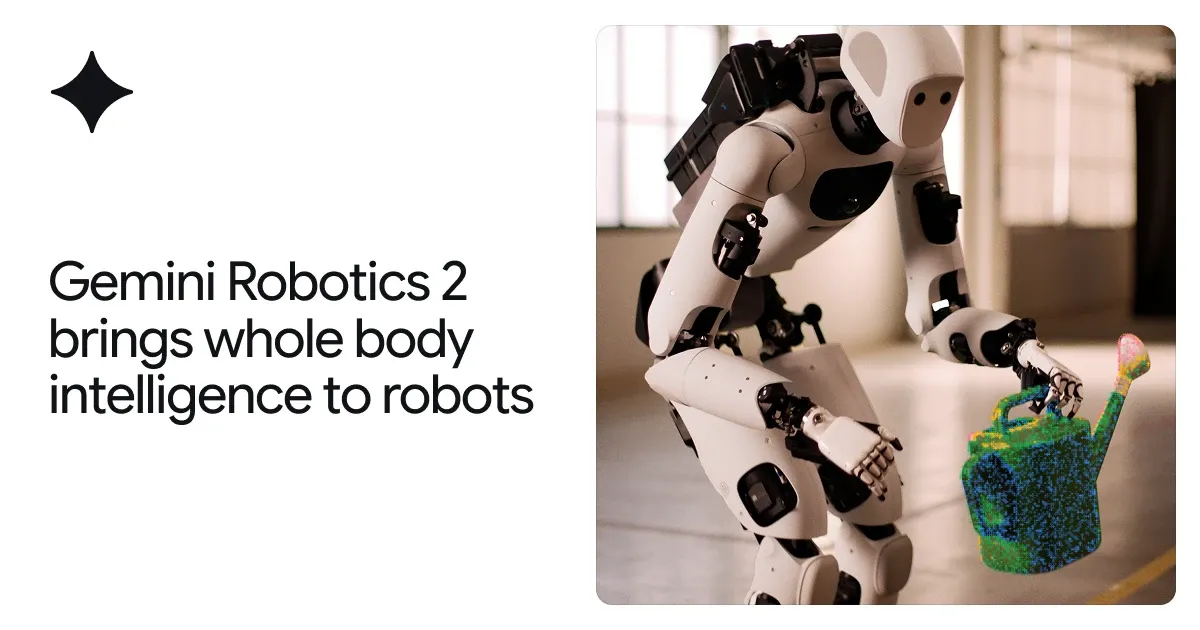
From feet to fingertips — we are teaching robots intelligent whole-body control, fine dexterity, and teamwork to complete a broad range of complex tasks.
Known for his clear and elegant writing style, Bertsekas shaped fields from control and optimization to large-scale computation and artificial intelligence.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.