Autonomous underwater vehicles (AUVs) operating in complex and uncertain ocean environments require reliable path-tracking and obstacle-avoidance capabilities to maintain safety in the presence of currents and obstacles. Traditional end-to-end deep reinforcement learning (DRL) methods often struggle with coupled navigation objectives, which can lead to oscillatory control and unreliable trajectory recovery. This paper proposes a modular dual-critic proximal policy optimization framework with prioritized experience replay (Modular DCPPO-PER) for AUV path tracking and collision avoidance. The framework separates navigation into two specialized policies for path tracking and collision avoidance and coordinates them through a time-to-collision-based soft risk arbitration mechanism. An actor-dual-critic-PER (ADCP) architecture is further introduced to improve learning stability and sample utilization by combining dual buffers with task-specific value estimation. In addition, a direction-sensitive reward function based on the sensor field of view assigns higher weights to high-risk perceptual regions and promotes smoother avoidance maneuvers. Simulation results in complex marine environments show that, compared with the advanced DRL baseline ARAB-PPO, the proposed method improves the average obstacle-avoidance success rate by 49.8% and reduces the path-tracking error by 12.9%. A USV-based physical surrogate experiment is also conducted to examine real-time inference, control continuity, and actuator-level feasibility on real hardware. The results indicate that the proposed framework can provide robust and smooth navigation behavior for AUV-oriented marine robotic applications, while full underwater AUV field validation remains future work.
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
This state-of-practice investigation was performed using a literature review followed by a multiple-case study approach and presents how inconsistency between managerial strategies and execution can lead to failure by means of a behavioral framework.
Carmine Giardino, Xiaofeng Wang, P. Abrahamsson· International Conference on...· 175 citations· ⚡19
This study conducts a case survey study based on the secondary data of the major pivots happened in 49 software startups, and demonstrates that customer need pivot is the most common among all pivot types.
Sohaib Shahid Bajwa, Xiaofeng Wang, Anh Nguyen-Duc et al.· Empirical Software Engineeri...· 127 citations· ⚡15
It is found that roles of MVPs in startups were not fully aware by entrepreneurs, and entrepreneurs should consider a systematic approach to fully explore the value of MVP, as a multiple facet product (MFP).
Anh Nguyen-Duc, P. Abrahamsson· International Conference on...· 93 citations· ⚡9
It is found that what perceived as biggest challenges by software startups do vary across different life cycle stages, even though its significance decreases when the learning focuses of the startups move from problem to solution and their products mature.
Xiaofeng Wang, Henry Edison, Sohaib Shahid Bajwa et al.· International Conference on...· 62 citations· ⚡6
A comprehensive overview of how enhanced sampling methods are reshaping the field, with a particular focus on the data-driven construction of collective variables, is provided.
Kai Zhu, Enrico Trizio, Jintu Zhang et al.· Chemical Reviews· 58 citations
Related blog posts
MIT News · Artificial Intelligence· news.mit.eduOct 27, 2026
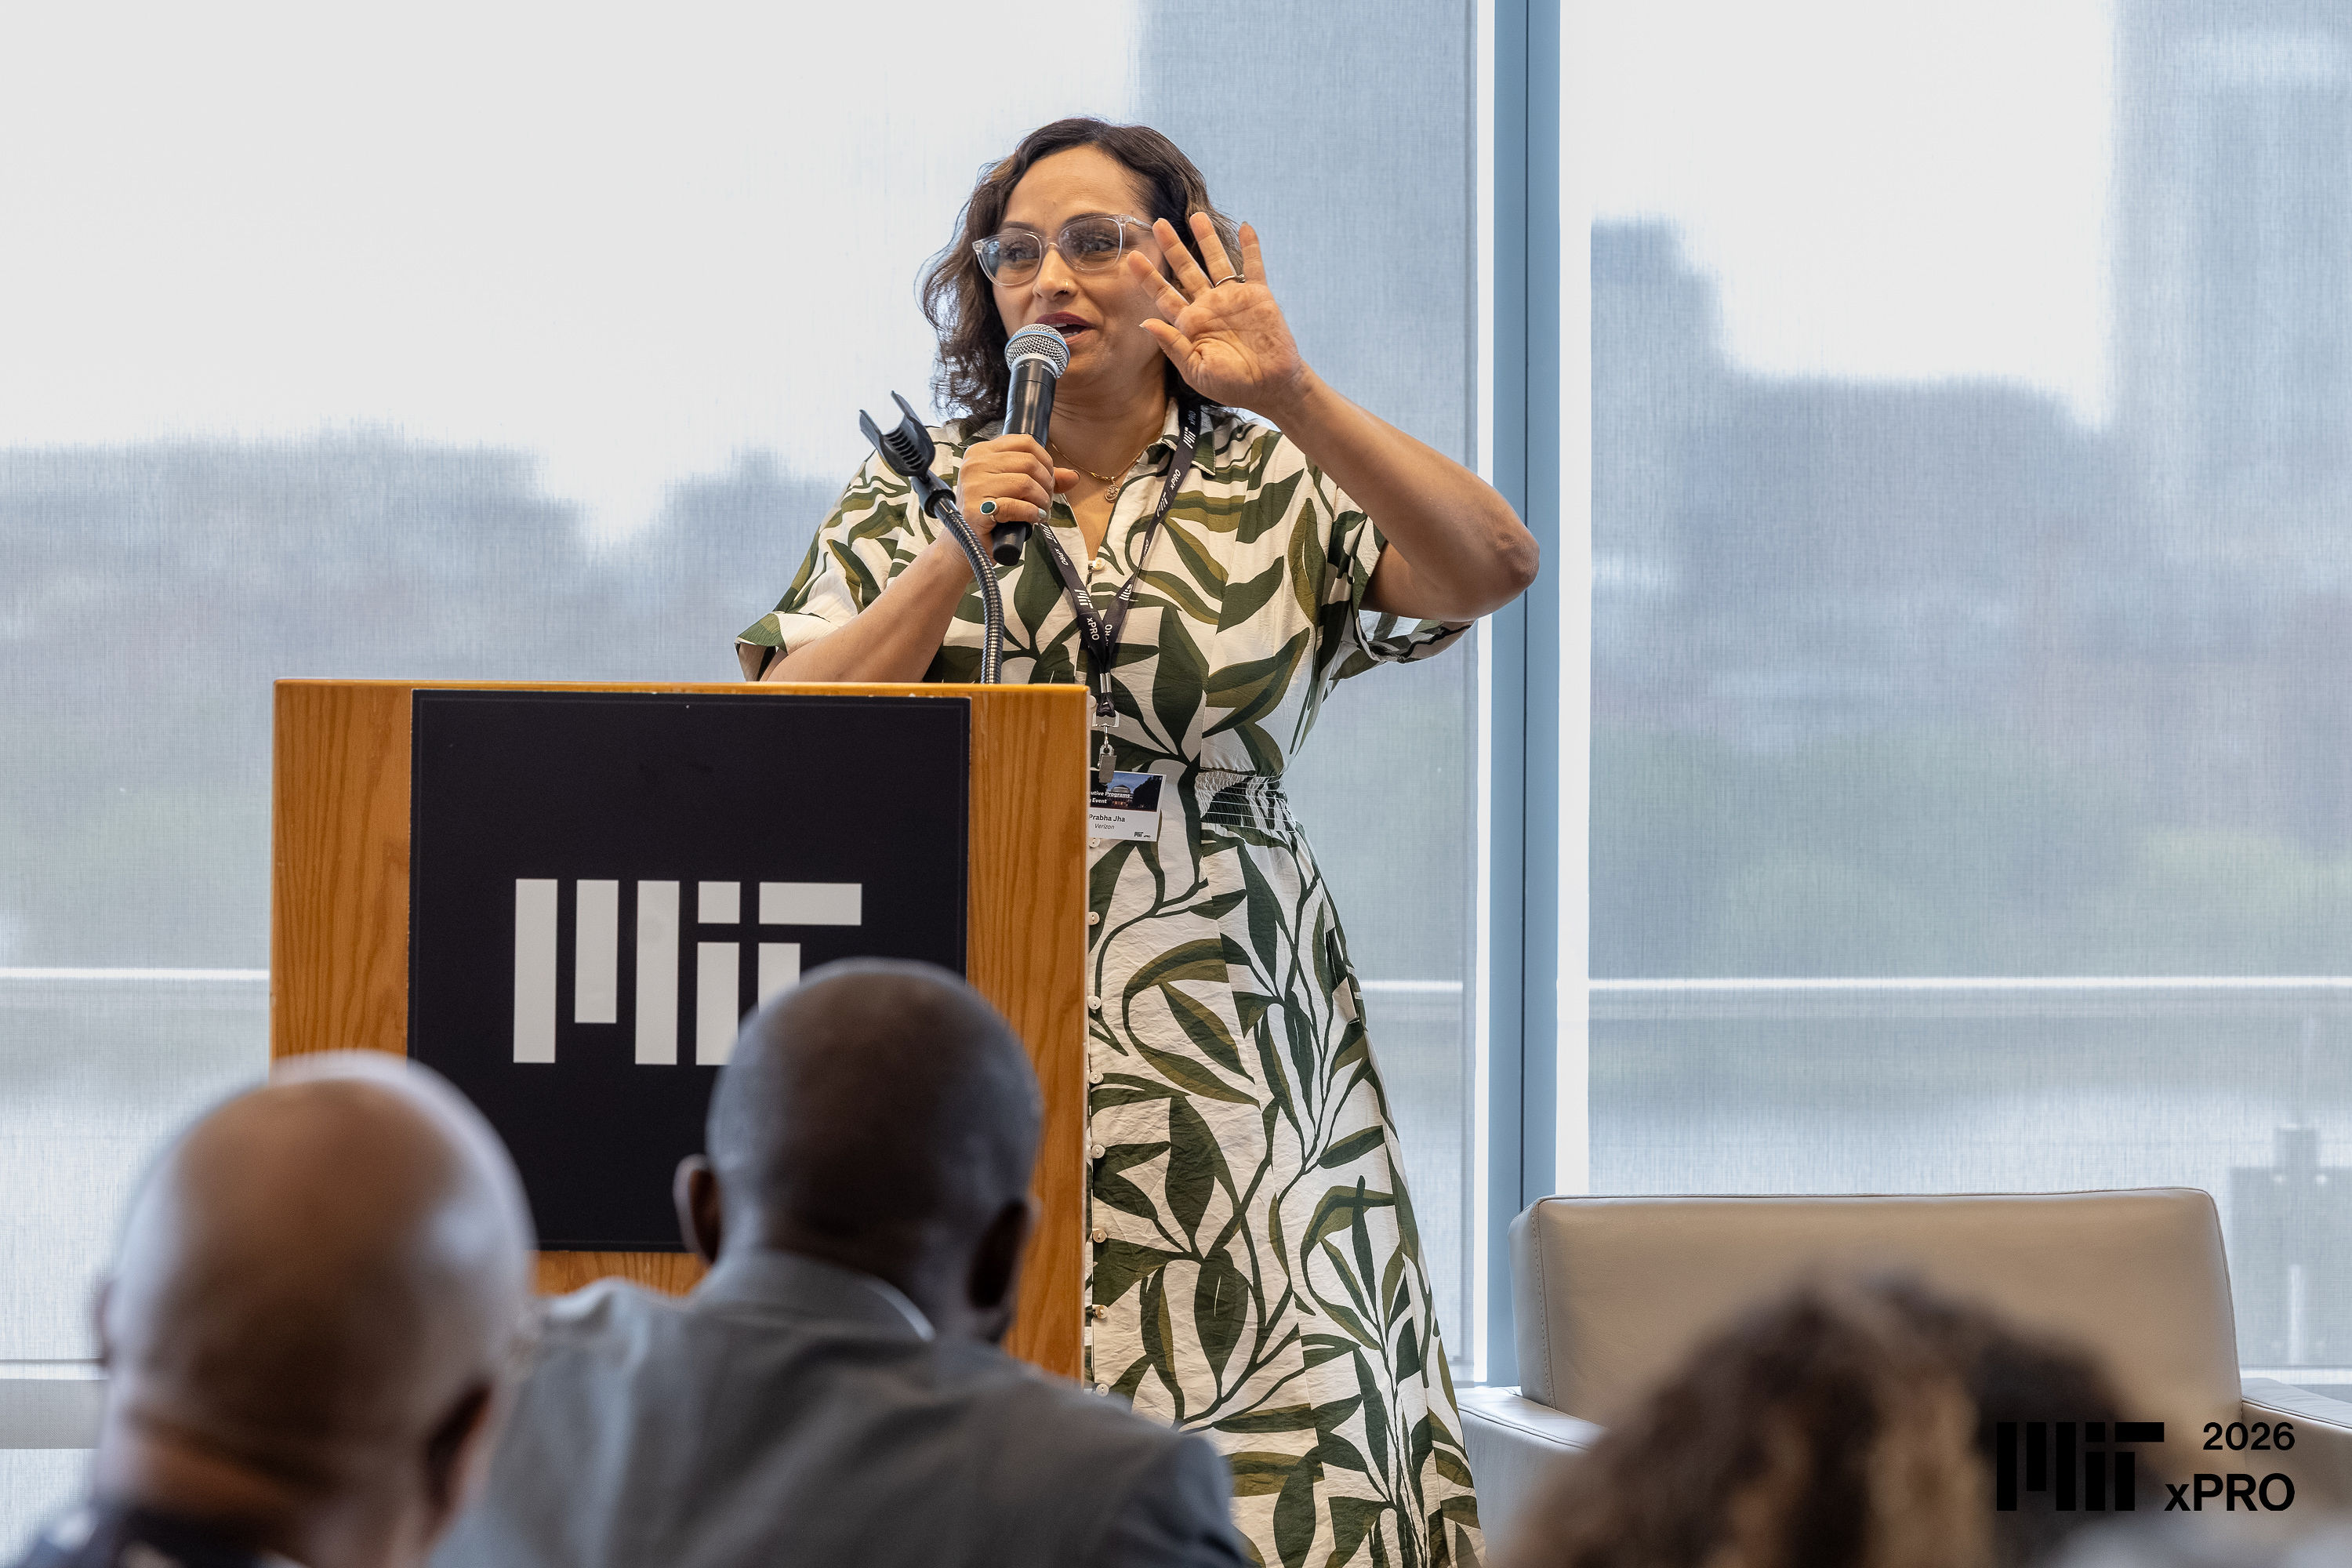
Prabha Jha used her experience with MIT Open Learning’s program for senior executives to develop AI solutions for her employer, Verizon, and to write a book.
Assistant Professor Benjamin Lindquist studies how engineers deliberately injected randomness into early AI, giving rise to deep-learning models that sometimes hallucinate.

