This work presents FleetScape, a Mixed Reality (MR) sandtable system that externalizes layered real-time mission, safety, and environmental data while enabling fluid transitions between manual intervention and autonomous supervision and shows that FleetScape supports situational awareness through layered spatial representations and clarifies control mode transitions.
Abstract
As autonomous drone deployments scale from individual units to coordinated swarms, the human operator's role shifts from direct piloting to high-level supervision. Current interfaces often treat multi-drone control as a scaled-up version of single-drone operation. We instead investigate how reframing fleet supervision as spatial interaction can better support the spatial, temporal, and safety demands of complex missions. We present FleetScape, a Mixed Reality (MR) sandtable system that externalizes layered real-time mission, safety, and environmental data while enabling fluid transitions between manual intervention and autonomous supervision. We developed a high-fidelity building inspection simulation that generates and streams synchronized multi-drone and environmental data for MR visualizations. We used this prototype to conduct a user study with six experienced drone pilots managing fleets of up to 15 drones. Our findings show that FleetScape supports situational awareness through layered spatial representations and clarifies control mode transitions. However, a limit to situational awareness was observed as fleet size increases, leading to different supervisory strategies. Finally, we derive design implications for supporting scalable drone fleet supervision.

Results show that an explicit context interface can support low-overhead runtime adaptation without modifying or retraining the perception model, and propose the context plane, a bounded, structured interface for runtime context.
Offshore maintenance requires operations in the air, the surface, and the subsea domain and include human supervision. This paper presents LOTUSim-Energy, a real-time maritime simulator designed for multi-domain human--drone interaction for offshore operation and maintenance. The plat- form unifies heterogeneous unmann...
J. Grosset, Marie Dubromel, Hélène Lechêne et al.· 0 citations
FlowPilot is a compact world-action model for real-time onboard UAV navigation from depth that jointly denoises future depth observations and executable trajectories with flow matching, and a dual-stream mixture-of-transformers couples video and action experts through shared attention, allowing future-scene prediction...
Run-Qing Wang, Ding Yu, Pengyuan Min et al.· 1 citation
Experimental results show that ROSE achieves competitive detection accuracy while providing improved robustness and cross-modal consistency across adverse weather scenarios, demonstrating strong generalization potential for roadside multi-modal perception under challenging environmental conditions.
Guo-Yu Zhang, Peng Hang, Xin Xia et al.· Communications in Transporta...· 0 citations
The results demonstrate the value of behavior-centered benchmarking and establish SIREN as an extensible data-generation and evaluation platform for autonomous-driving and transportation safety research.
Yi-Chen Zhu, Tian Zhao, Haoxin Leng et al.· 0 citations
This paper studies 3D multi-UAV path planning and task assignment under uncertain ground PoI demands, and proposes FORTUNE, a hierarchical offline-online framework that consistently outperforms state-of-the-art methods in effectiveness, scalability, and practical applicability.
Minghui Liwang, Wen-Han Jia, Xin-Lei Yi et al.· 0 citations
Related blog posts
MIT News · Artificial Intelligence· news.mit.eduOct 28, 2026
Professor Paris Smaragdis develops computers with superhuman hearing for applications like speech recognition, music understanding, and environmental monitoring.
MIT News · Artificial Intelligence· news.mit.eduOct 23, 2026
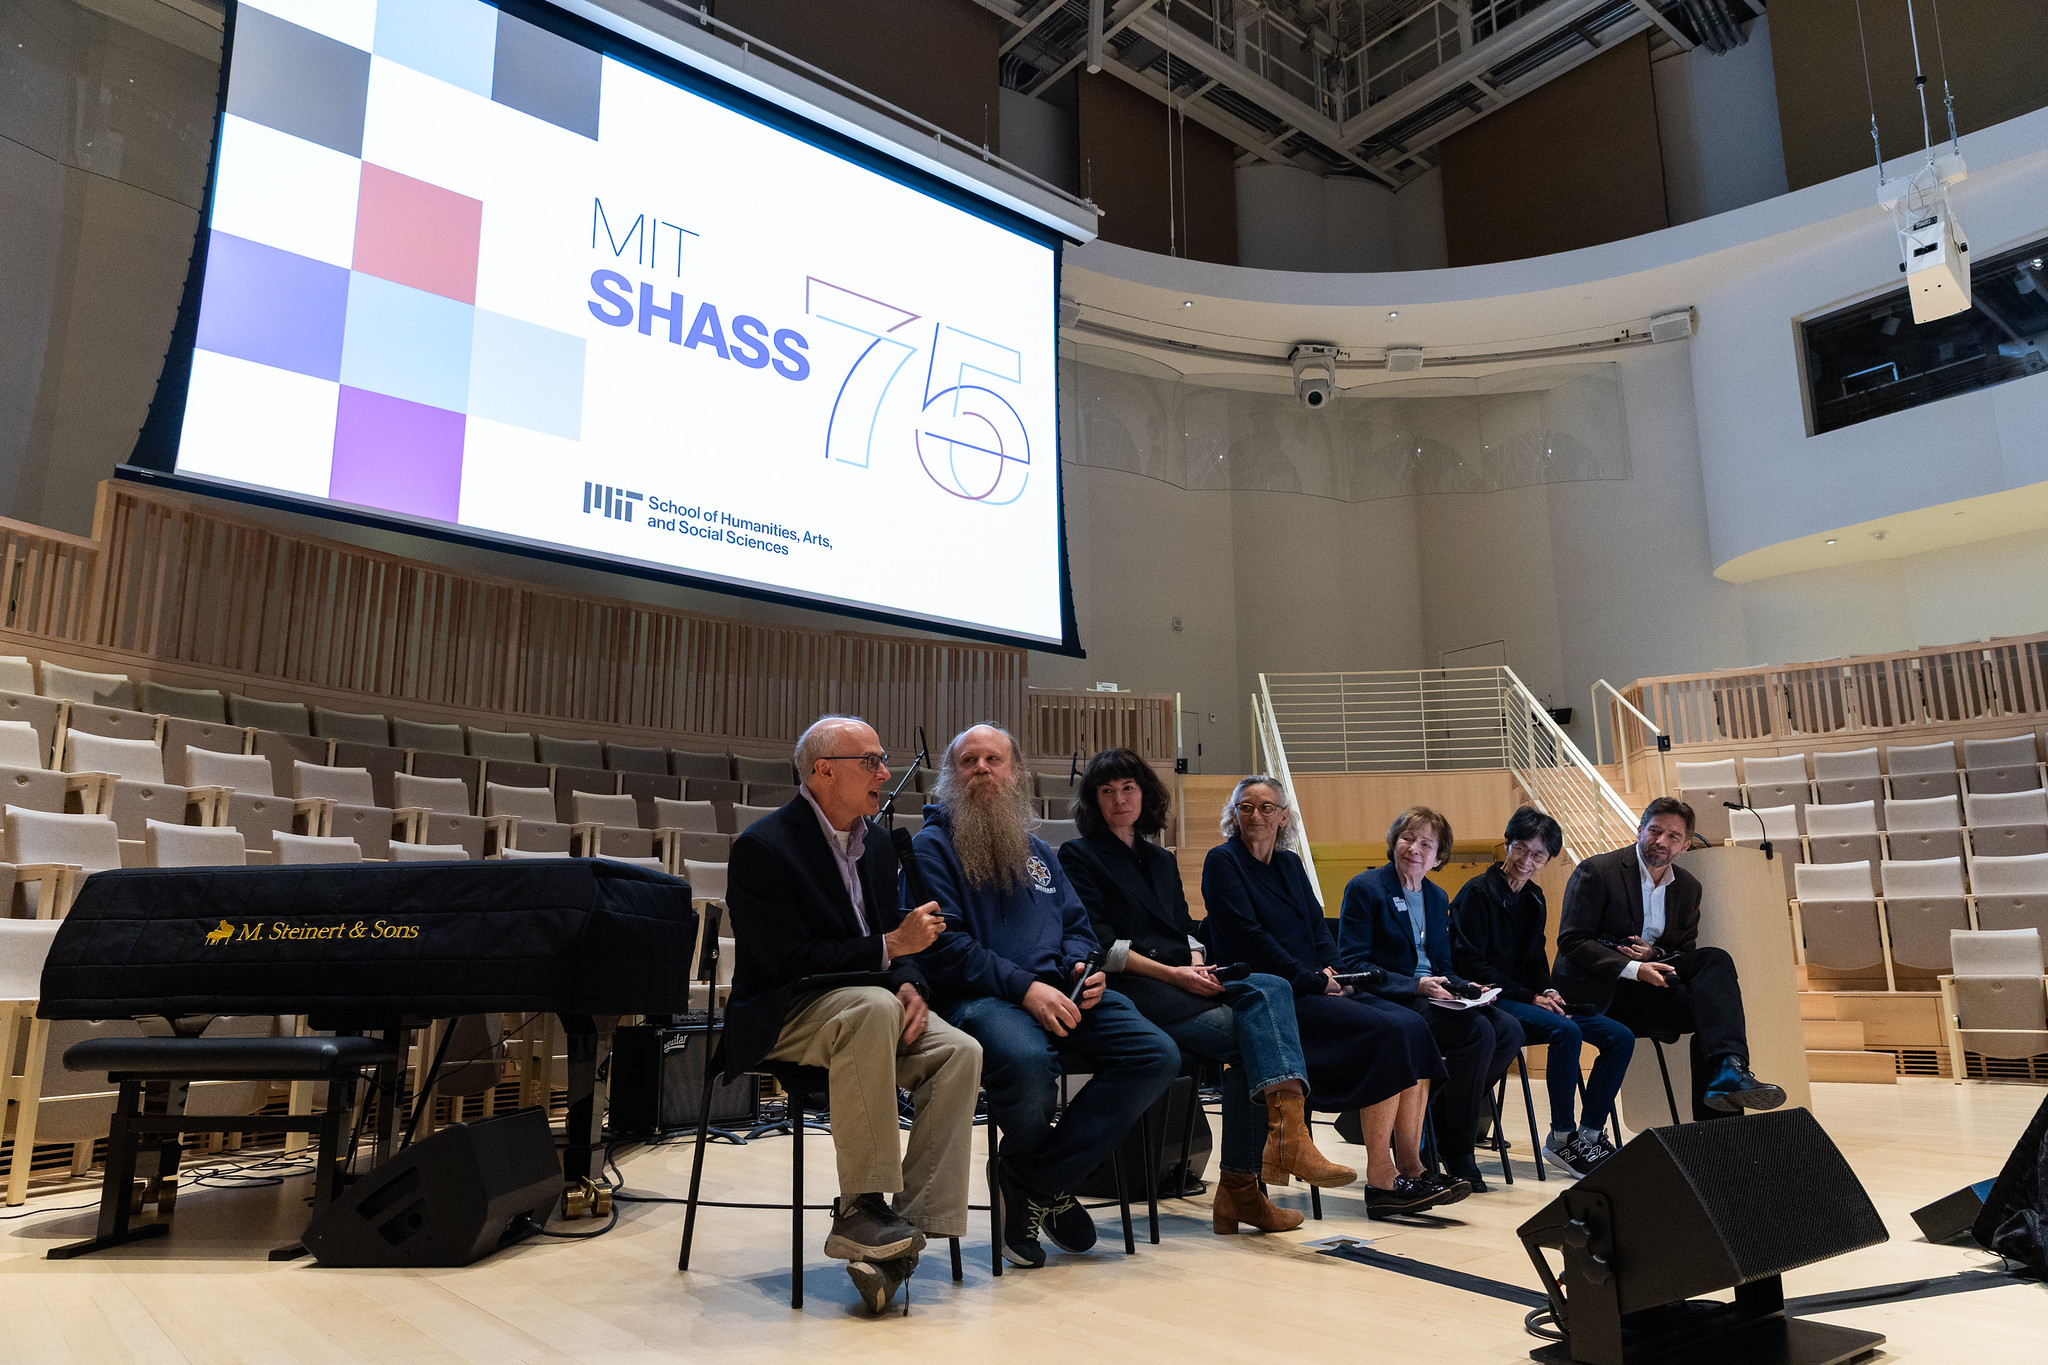
During the School of Humanities, Arts, and Social Sciences’ 75th Anniversary Symposium, President Sally Kornbluth said “MIT has never needed your particular insight and guidance more than we do now.”
MIT News · Artificial Intelligence· news.mit.eduOct 23, 2026
Assistant Professor Benjamin Lindquist studies how engineers deliberately injected randomness into early AI, giving rise to deep-learning models that sometimes hallucinate.
MIT News · Artificial Intelligence· news.mit.eduOct 22, 2026
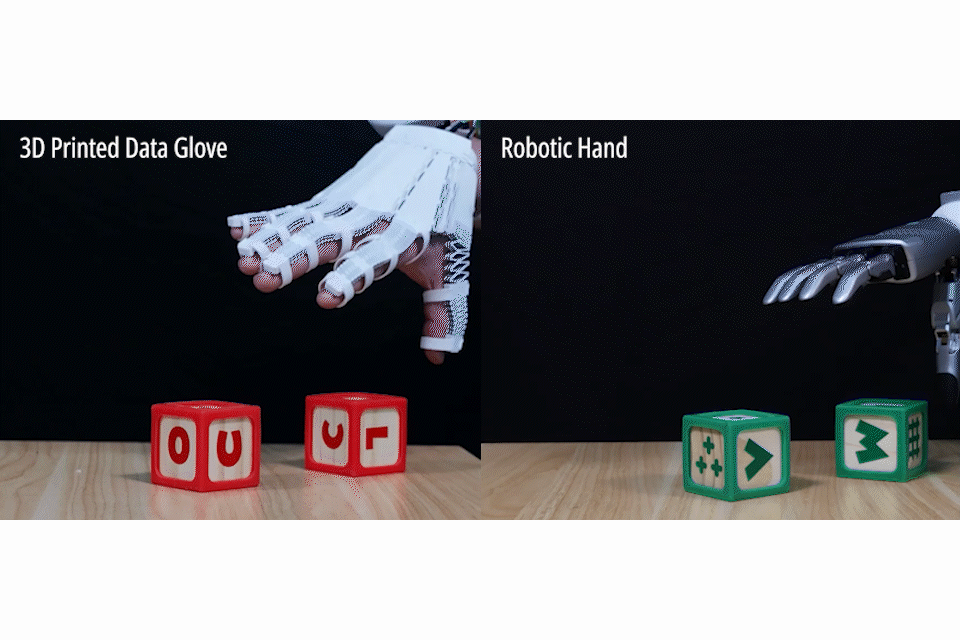
“X-Hinges” helps design and 3D print items like lamps and gloves with an interactive twist: automatically embedded sensors that perceive and adaptively respond to human contact.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.