Skip to content
#edge computing Open access

A Lightweight Asymmetric RGB–Thermal Multi-Scale Detection Network for UAV Forest Fire Monitoring

Oct 2026 · Electronics · Vol 15, pp. 4554 · 0 citations · 32 references
Fire Detection and Safety Systems

TL;DR

YOLO-ATF, a lightweight asymmetric RGB–thermal multi-scale detection network built upon RepViT, provides a low-cost, high-accuracy, and deployable solution for early forest fire detection on computationally constrained UAV platforms.

Abstract

Forest fires pose severe threats to ecological systems and human safety, yet existing UAV-based detectors struggle to balance accuracy and real-time performance due to severe target scale variations and limited edge computing resources. This paper proposes YOLO-ATF, a lightweight asymmetric RGB–thermal multi-scale detection network built upon RepViT. The model adopts a full-resolution RGB stream paired with a half-capacity infrared stream to leverage complementary visible texture and thermal signals. Three key components are introduced: a P2 high-resolution detection head (stride 4) for tiny fires, a cross-modal feature aggregation network (FAN) with channel-gated residual refinement, and a thermal-guided low-frequency attention (TLA) module, which provide the major gains. A cross-modal alignment loss (CWA) and a parameter-free SimAM module serve as auxiliary components without increasing inference overhead. On the RGBT-3M single-class fire protocol, YOLO-ATF achieves 97.03% mAP@0.5 and 61.03% mAP@0.5:0.95 on the validation set, with only 4.02M parameters and 38.72 GFLOPs under 640 × 640 input, comprehensively outperforming mainstream lightweight detectors and other state-of-the-art fire detectors. The proposed method provides a low-cost, high-accuracy, and deployable solution for early forest fire detection on computationally constrained UAV platforms.

Read PDF

Similar papers

Open access Sep 2026

A Lightweight Forest Fire Detection Model with Multi-Granularity Vision-Language Enhancement

In recent years, Unmanned Aerial Vehicle (UAV)-based object detection technology has demonstrated immense potential for forest fire monitoring in complex environments. However, constrained by the drastic multi-scale variations in fire targets, severe background interference, and the limited computational resources of e...

Yi-Fan Ma, Weifeng Shan, Yan-Wei Sui et al. · 0 citations
Open access Aug 2026

MSF-YOLO: A Multi-Scale Feature Enhancement Network for Tiny Fire Spot Detection in UAV Forest Images

Tiny fire spot detection in UAV images under complex forest backgrounds remains challenging due to tiny target size, sparse distribution, weak feature responses, and background interference. This paper proposes a Multi-Scale Feature Enhancement Network (MSF-YOLO) for tiny fire spot detection. Specifically, a lightweigh...

Tao Yue, Hong Huang, Bo Song et al. · 0 citations
Open access Oct 2026

Wavelet Interactive Mamba Fusion Network for UAV Small Object Detection with Visible–Thermal Data

Accurate small object detection in low-altitude unmanned aerial vehicle (UAV) visible–thermal (RGB-T) scenarios remains challenging under complex illumination and background clutter due to thermal noise, weak cross-modal interaction, and attenuation of ultra-small target features. This paper proposes Wavelet Interactiv...

Qi-Chao Gao, Tian-Wen Guo · 0 citations
Open access Aug 2026

A lightweight deep learning framework for early fire and smoke detection in forest fire monitoring

FRW-YOLOv8, a lightweight YOLOv8-based model for fire and smoke detection in UAV-perspective forest scenes is proposed and FasterNeXt is introduced into the backbone to reduce redundant computation while preserving feature representation.

Jie Hu, Zi-Shuai Jia, Jiaxin Feng et al. · 1 citation
Conference Sep 2026

A low-light RGB-thermal infrared target detection algorithm based on adaptive cross-modal fusion and multiscale feature enhancement

Small-object detection under low illumination remains a persistent challenge in aerial surveillance, nighttime patrol, and safety-critical vision tasks, where single-modality sensors—RGB or infrared alone—provide degraded or incomplete target information. This paper proposes an RGB-T object detection network that combi...

Xin Song, Jian-Jun Luo, Ping Wang · 0 citations

Related blog posts

Microsoft Research Blog Oct 21, 2026

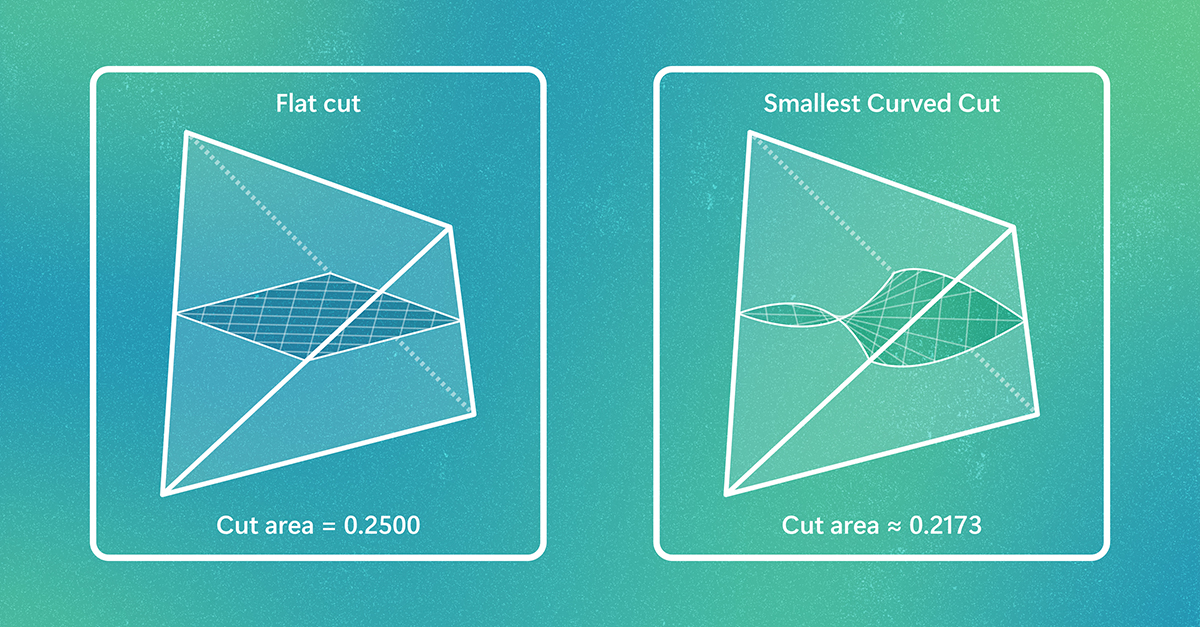
Solving a 31-year-old grand challenge in mathematics – the KLS conjecture

For decades, a fundamental question about the difficulty of computing in high-dimensional spaces has resisted proof. New research resolves this question, removing a major theoretical obstacle to understanding the efficiency of randomized algorithms used across science and computing. The Kannan–Lovász–Simonovits (KLS) conjecture was proposed in 1995. It asks whether, for a broad class of high-dimensional […] The post Solving a 31-year-old grand challenge in mathematics – the KLS conjecture appear…

MIT News · Artificial Intelligence Oct 15, 2026

AI model decodes the language cells use to communicate

A new computational approach reveals how cells communicate to assemble into tissues. This could accelerate stem cell engineering, improve disease models, and inform therapies.

Microsoft Research Blog Oct 15, 2026

Proof-based general-purpose computing with Magnetar

Zero-knowledge proofs can verify computing results without rerunning workloads or exposing sensitive data. Magnetar helps bring them into the mainstream with support for standard programming languages, major speed gains, and quantum-resistant security. The post Proof-based general-purpose computing with Magnetar appeared first on Microsoft Research.

We use cookies to run the site and, with your consent, for analytics and to show ads. See our Cookie Policy.