Humanoid loco-manipulation in dynamic scenes is non-Markovian: cues vanish as objects change or are hidden, or leave the view as the robot turns and walks, yet whole-body vision-language-action (VLA) policies see only the present. We present WholeBodyMem, an object-guided perceptual memory that keeps the pre-history of object events seen before the robot acts on its goal. SAM3 tracks the task objects, and their events causally select key frames within an adaptive budget, which the action expert reads by cross-attention together with object tokens encoding appearance, geometry and time. We also contribute HuMeGo, a humanoid memory benchmark with six simulated and six real-world Unitree G1 tasks. Keeping the right frames rather than more frames, WholeBodyMem surpasses memoryless and uniform-memory baselines, raising its base policy's success from 29.1% to 72.6% in simulation and from 36.7% to 88.3% on the real robot, while also improving the standard SIMPLE tasks (70.2% to 86.9%).
This paper investigates developing real-world perception for active agents, proposes Gibson Environment for this purpose, and showcases a set of perceptual tasks learned therein.
F. Xia, Amir Zamir, Zhi-Yang He et al.· 2018 IEEE/CVF Conference on...· 1,069 citations· ⚡112
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
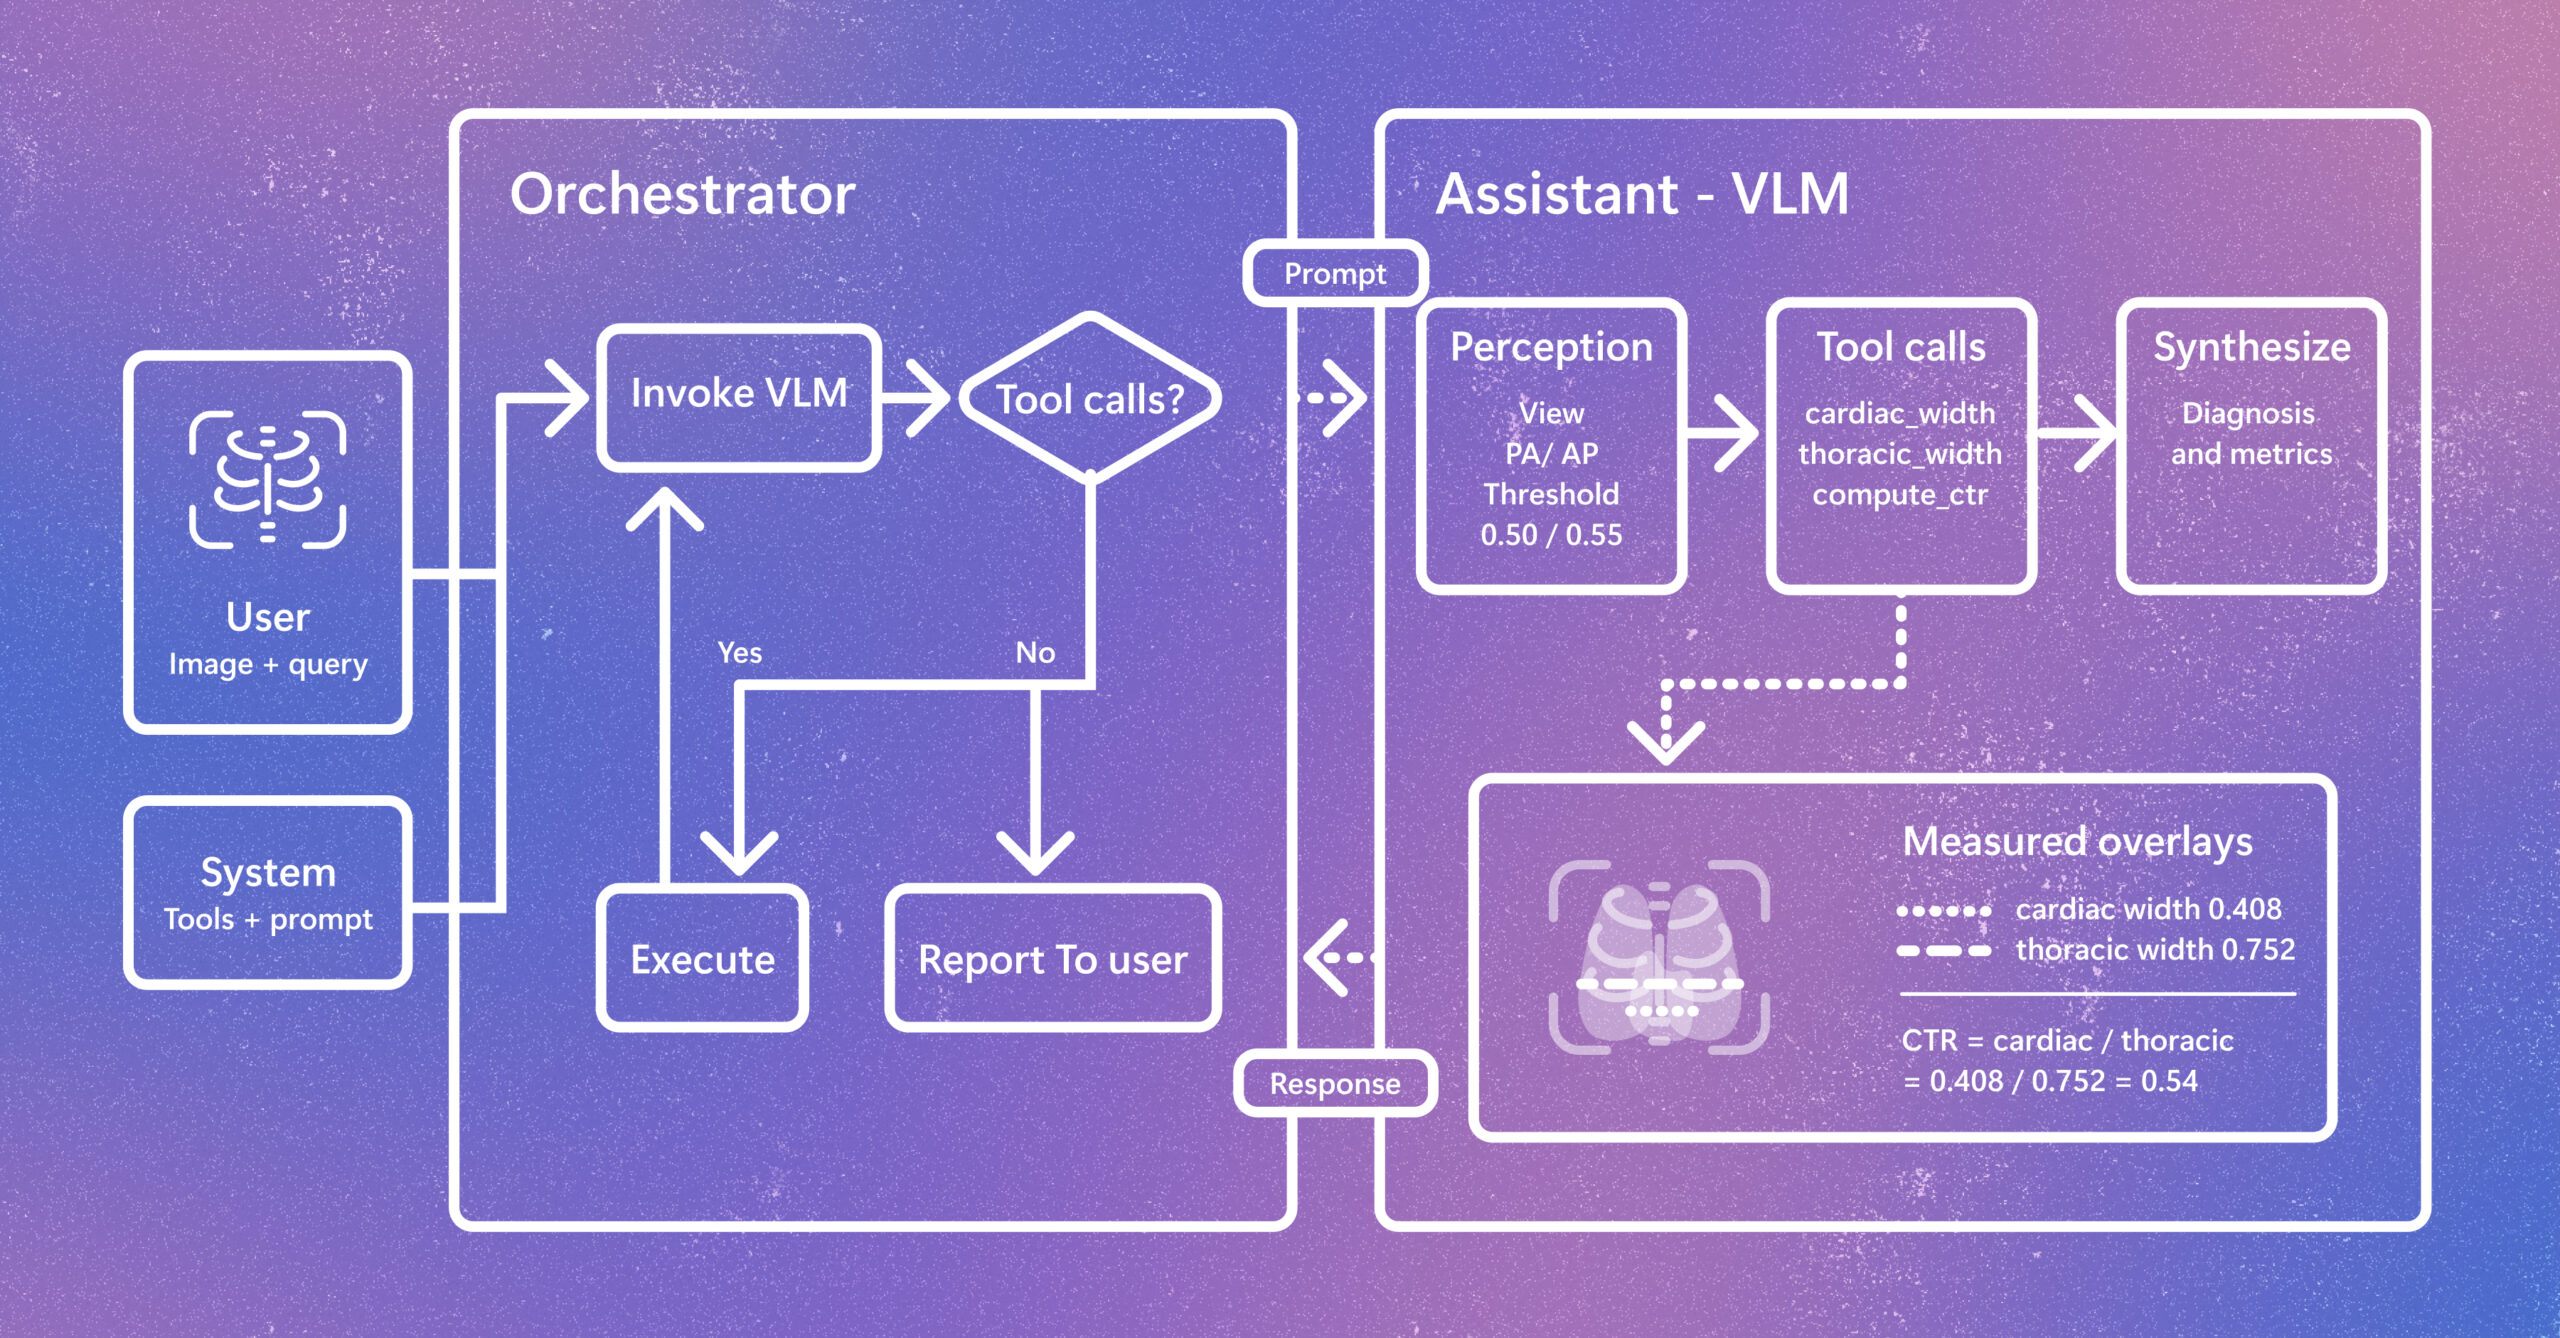
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.