As scaling pre-training data alone yields diminishing returns, post-training is becoming increasingly important across physical AI domains such as autonomous driving. End-to-end driving policies are pre-trained in open loop with behavior cloning on human demonstrations. However, compounding errors during closed-loop deployment can take the vehicle outside the training data distribution, increasing the risk of safety-critical incidents. Closed-loop post-training can mitigate this risk but requires costly simulation for sensor-based policies. We propose OPTED (on-policy fine-tuning for end-to-end driving) which decouples reinforcement learning from the post-training of the end-to-end policy: a privileged teacher is trained using RL on vectorized inputs (HD-map and bounding boxes). This teacher then provides supervision to the pre-trained student during closed-loop post-training. We apply OPTED to two camera-based models, TransFuser and VaVAM, and fine-tune them in AlpaSim, using neural reconstructions (3DGS) of real driving logs. Driving scores increase by factors of 1.6$\times$ and 9.5$\times$, respectively. In controlled experiments OPTED matches closed-loop performance with approximately three orders of magnitude fewer simulator interactions than direct RL post-training, while staying closer to the human prior. Project page: https://01dami23.github.io/opted/
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
It is proved that any global minimizer of the trajectory balance objective can define a policy that samples exactly from the target distribution, and empirically demonstrate the benefits of the trajectories balance objective for GFlowNet convergence, diversity of generated samples, and robustness to long action sequenc...
Esmeralda S. Whitammer, Moksh Jain, Emmanuel Bengio et al.· Neural Information Processin...· 302 citations· ⚡60
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
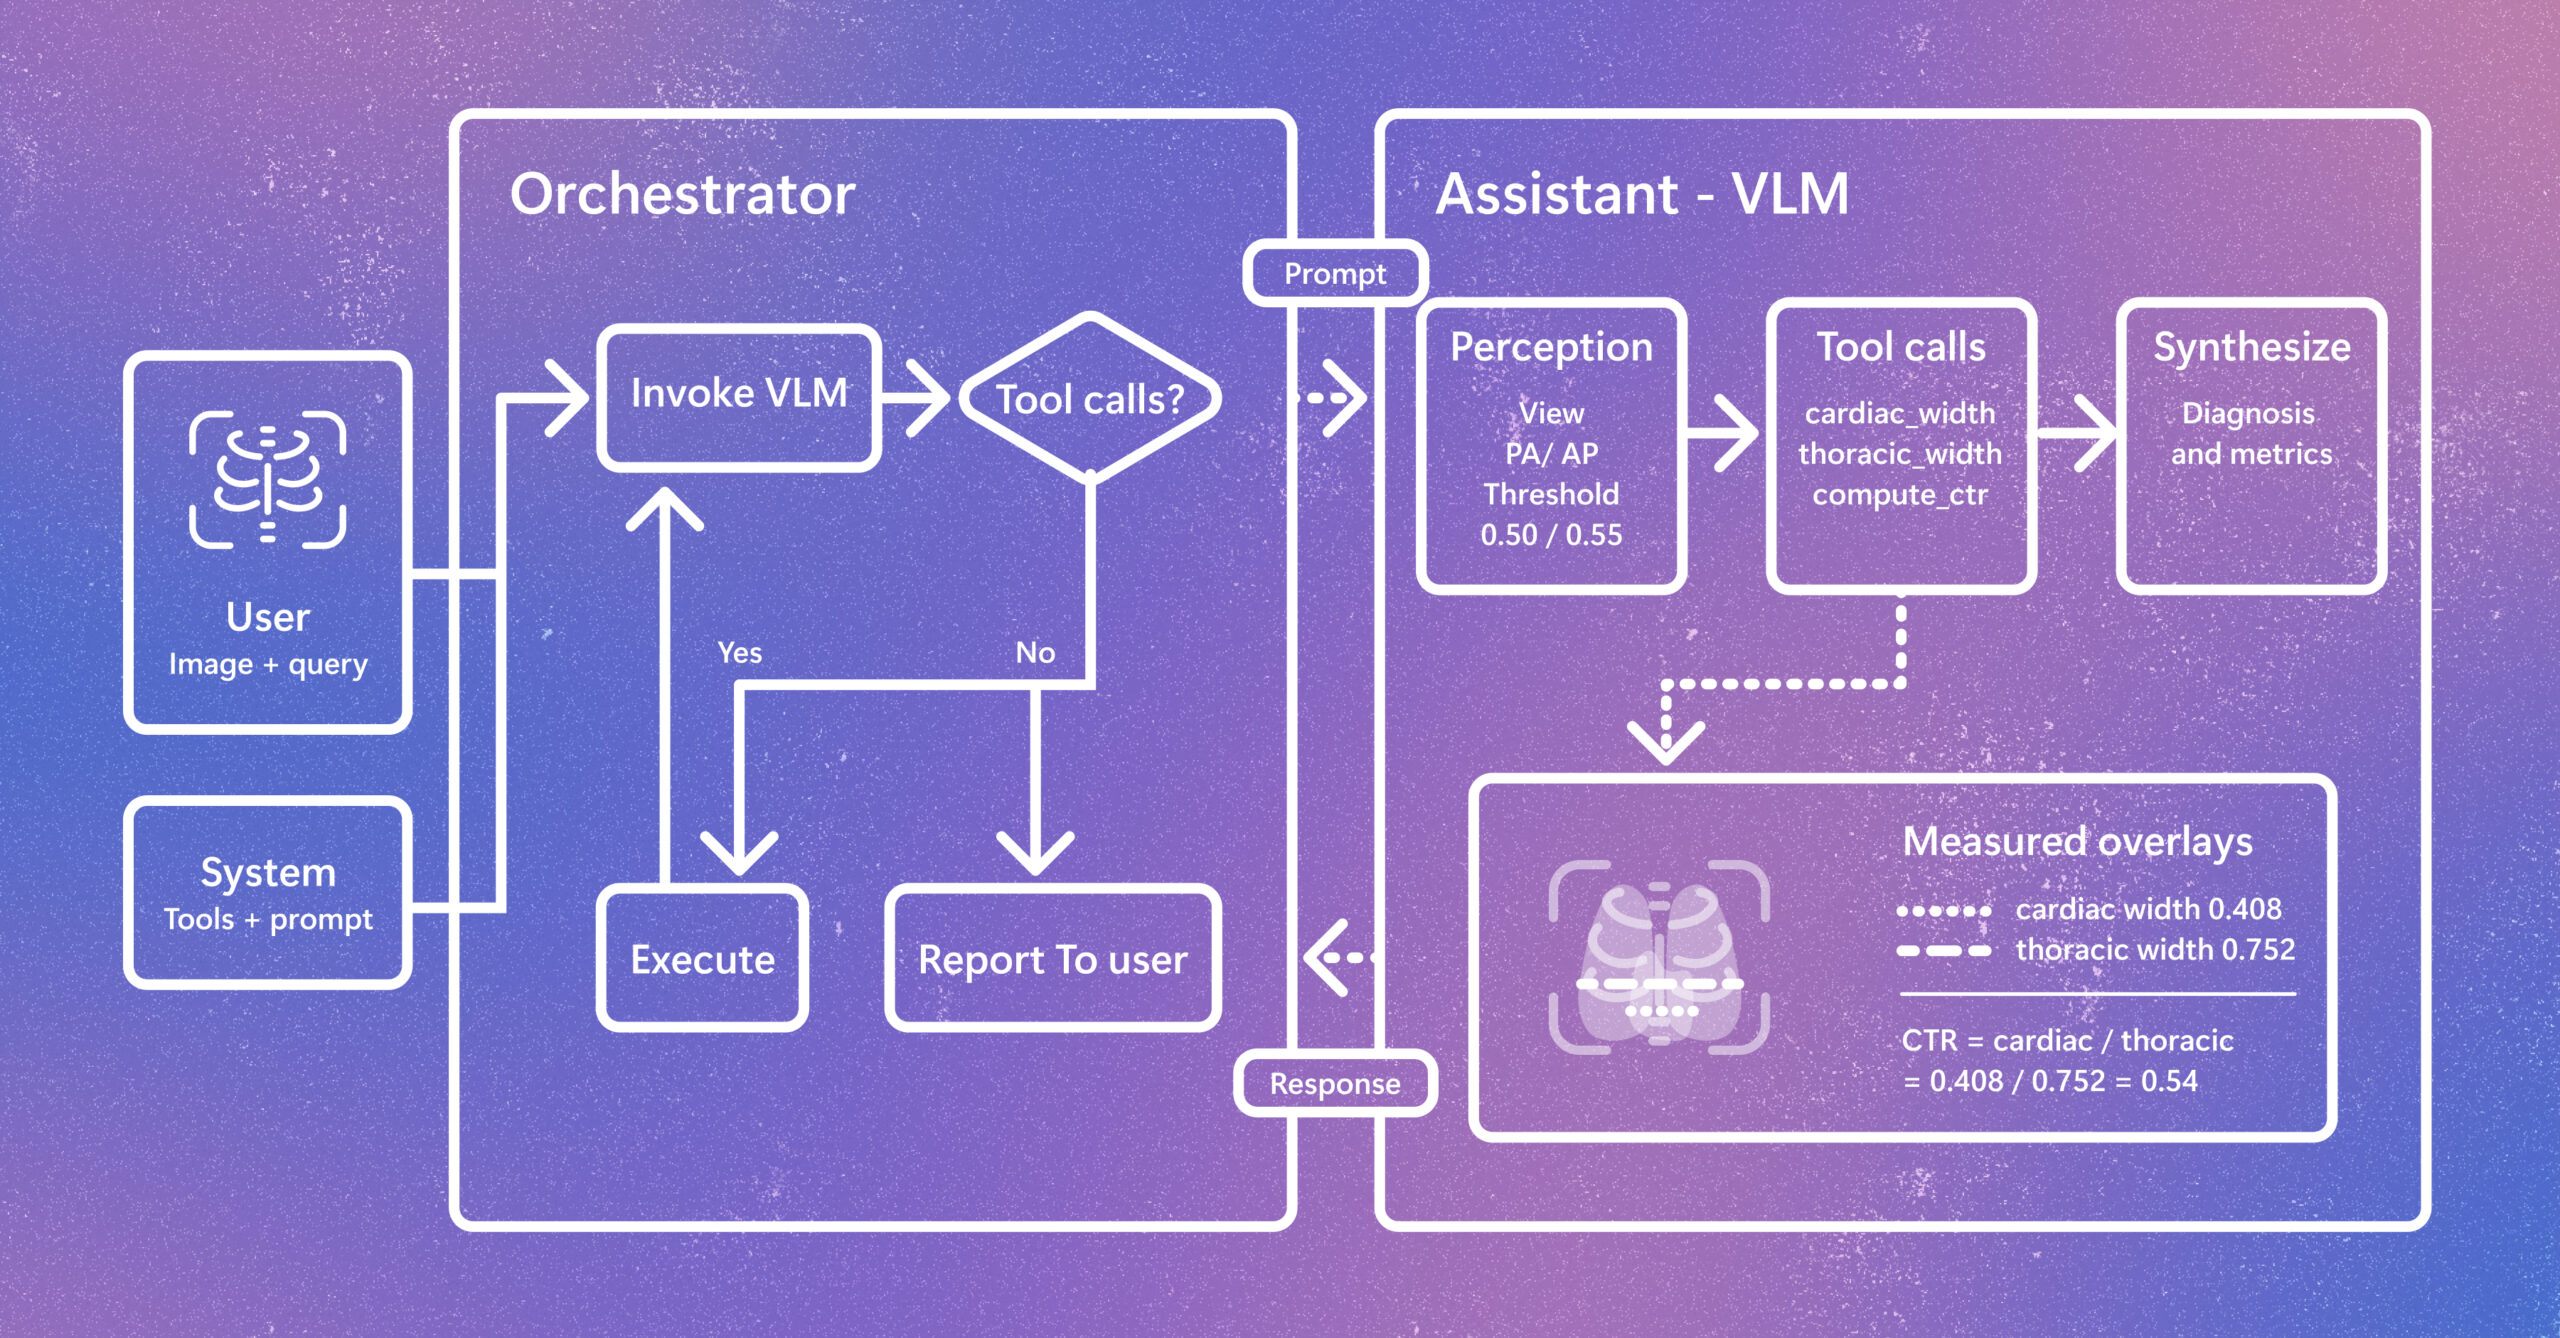
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.