This work proposes a deep learning-based search-space reduction pipeline (SRP) that integrates a module called MazeNet to solve indoor navigation tasks with fast runtimes while maintaining accuracy, and evaluates MazeNet’s runtime and path-length performance using a variety of planning methods against both exact and approximate graph algorithms in simulations and in real-life floor plans.
Abstract
Connecting multiple destinations with the shortest overall path in an obstacle-rich indoor environment is a classic problem in robotic path planning. Established solutions, such as A*, ARA*, and RRT*, execute faster when given smaller input maps that exclude extraneous paths. However, removing such paths without losing the ground truth solution is challenging because runtime-efficient approximations can yield detours. This work proposes a deep learning-based search-space reduction pipeline (SRP) that integrates a module called MazeNet to solve indoor navigation tasks with fast runtimes while maintaining accuracy. We transform the indoor environment into a graph representation, reducing the planning task into a graph-based optimization problem known as the Obstacle-Avoiding Rectilinear Steiner Minimum Tree. MazeNet takes compressed images derived from graph abstractions as inputs and uses a recurrent convolutional neural network trained to predict the shortest feasible path connecting all destinations. Within SRP, MazeNet’s output restricts the search space for classical planners. MazeNet solves more complex instances than those seen during training via recurrence with an integrated termination condition. We evaluate MazeNet’s runtime and path-length performance using a variety of planning methods against both exact and approximate graph algorithms in simulations and, after fine-tuning, in real-life floor plans. MazeNet solves all these specific test cases with improved runtimes and no increase in path length. Physics simulation further supports SRP’s feasibility across the tested floor plans, with no collisions recorded during navigation tasks.
Agile methods continue to gain popularity. In particular, the Scrum method appears to be on the verge of becoming a de-facto standard in the industry, leading the so called Agile movement. While there are success stories and recommendations, there is little scientifically valid evidence of the challenges in the adoptio...
A. Marchenko, P. Abrahamsson· Agile Conference· 59 citations· ⚡11
A comprehensive taxonomy of the challenges faced when a medium-scale organization decided to adopt software platforms is provided, namely: business challenges, organizational challenges, technical challenges, and people challenges.
Yaser Ghanam, F. Maurer, P. Abrahamsson· Information and Software Tec...· 41 citations· ⚡3
It is shown that high article processing charges are not sufficiently justified by the publishers, which often lack transparency and may prevent authors from adopting OA.
D. Graziotin, Xiaofeng Wang, P. Abrahamsson· Scientometrics· 21 citations· ⚡1
MCGLPPI, a novel geometric representation learning framework that combines graph neural networks (GNNs) with the MARTINI molecular coarse-grained (CG) model to predict overall PPI properties accurately and efficiently, offers an effective and efficient solution for PPI overall property predictions.
Yang Yue, Shu Li, Yihua Cheng et al.· bioRxiv· 15 citations
PepPCBench enables a robust evaluation of PFNN-based methods and supports their continued development for peptide-protein structure prediction, and highlights the influence of peptide length, conformational flexibility, and training set similarity on prediction accuracy.
Si-Long Zhai, Huifeng Zhao, Ji-Ke Wang et al.· Journal of Chemical Informat...· 13 citations· ⚡1
OmniMol is presented, a framework using hypergraphs to improve predictions of molecular properties, addressing challenges of imperfect data annotation and enhancing model explainability, and achieves state-of-the-art performance in properties prediction.
Assistant Professor Pat Pataranutaporn describes a new interface that lets everyday users glimpse inside an AI's neural network before their chatbot ever says a word.
Microsoft Research Blog· microsoft.comJul 13, 2026
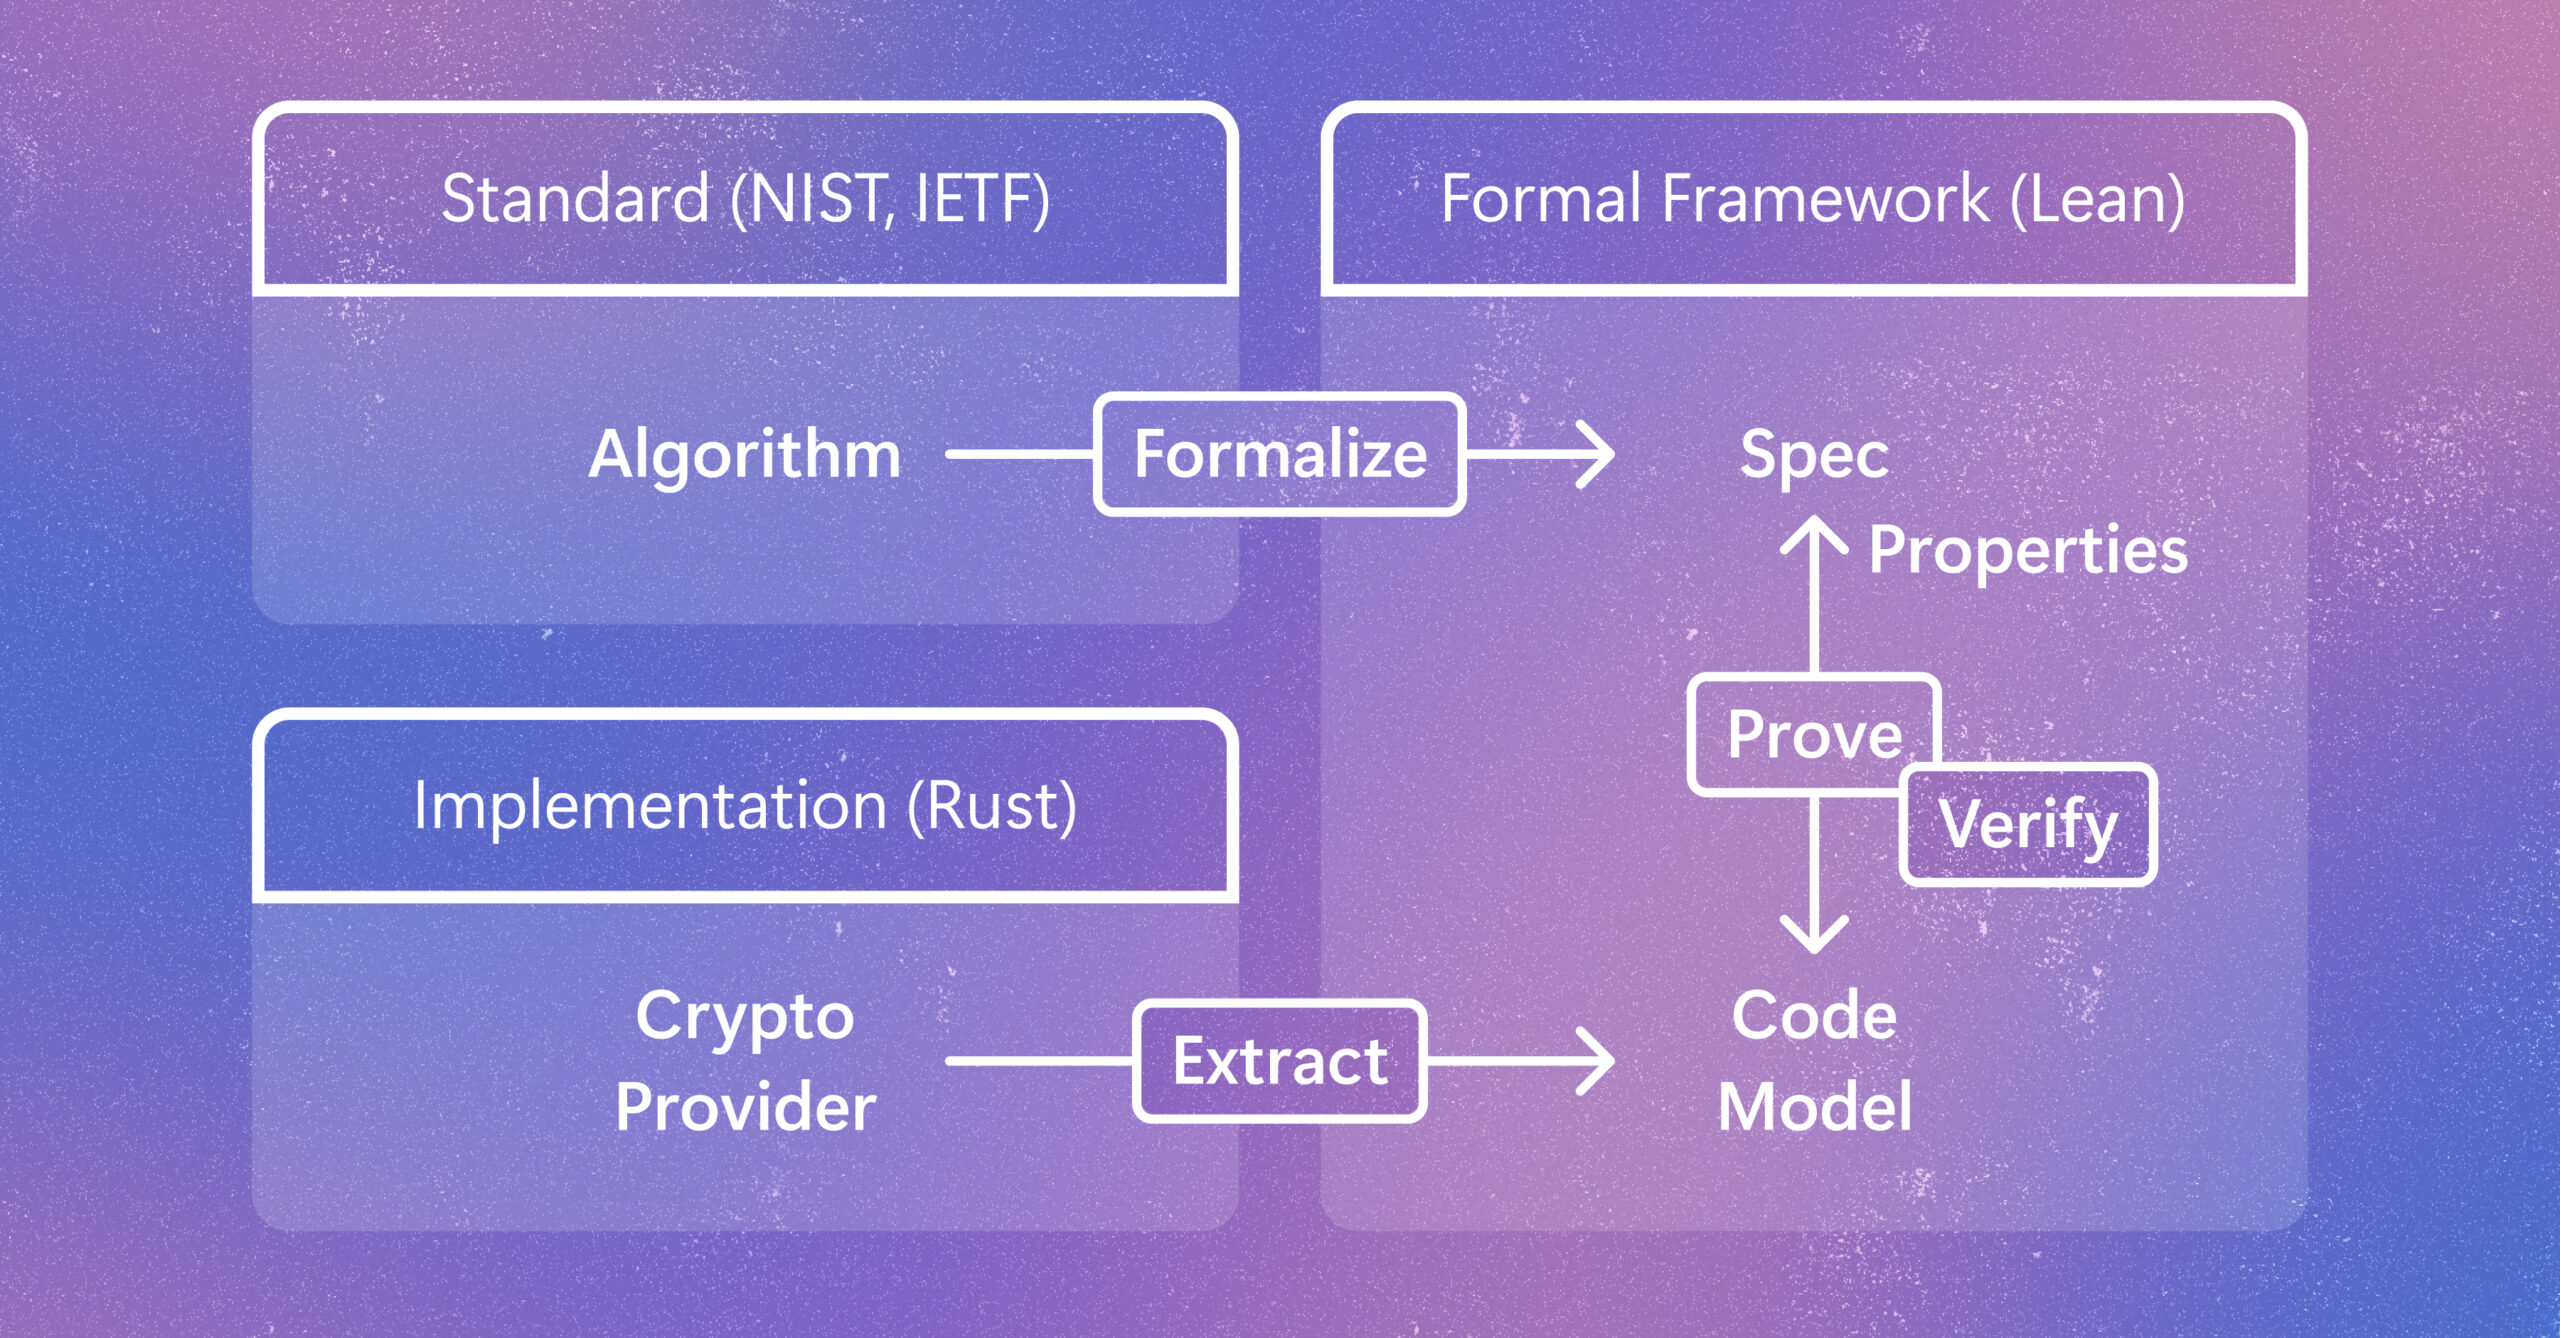
Cryptographic code supports vital protections in modern computing systems. Learn how a new method helps verify code as developers write it while preserving speed and adaptability as it gets implemented and evolves. The post Verifying Rust cryptography in SymCrypt, from standards to code appeared first on Microsoft Research.
MIT News · Artificial Intelligence· news.mit.eduJul 6, 2026
PhD student Rachel Sava, winner of the Envisioning the Future of Computing Prize, explores transformative improvements and dystopian risks of neural technology.